Embodied AI

Embodied AI data collection, built to your spec.

World models, VLAs, and robot policies learn from how people actually move through tasks. We collect those demonstrations first-person, aligned across every sensor, in the tasks and places your model needs, on demand.
Capture
Egocentric + wrist
Labels
Hand pose · actions · contacts
First batch
Median 48 h
Formats
RLDS · LeRobot
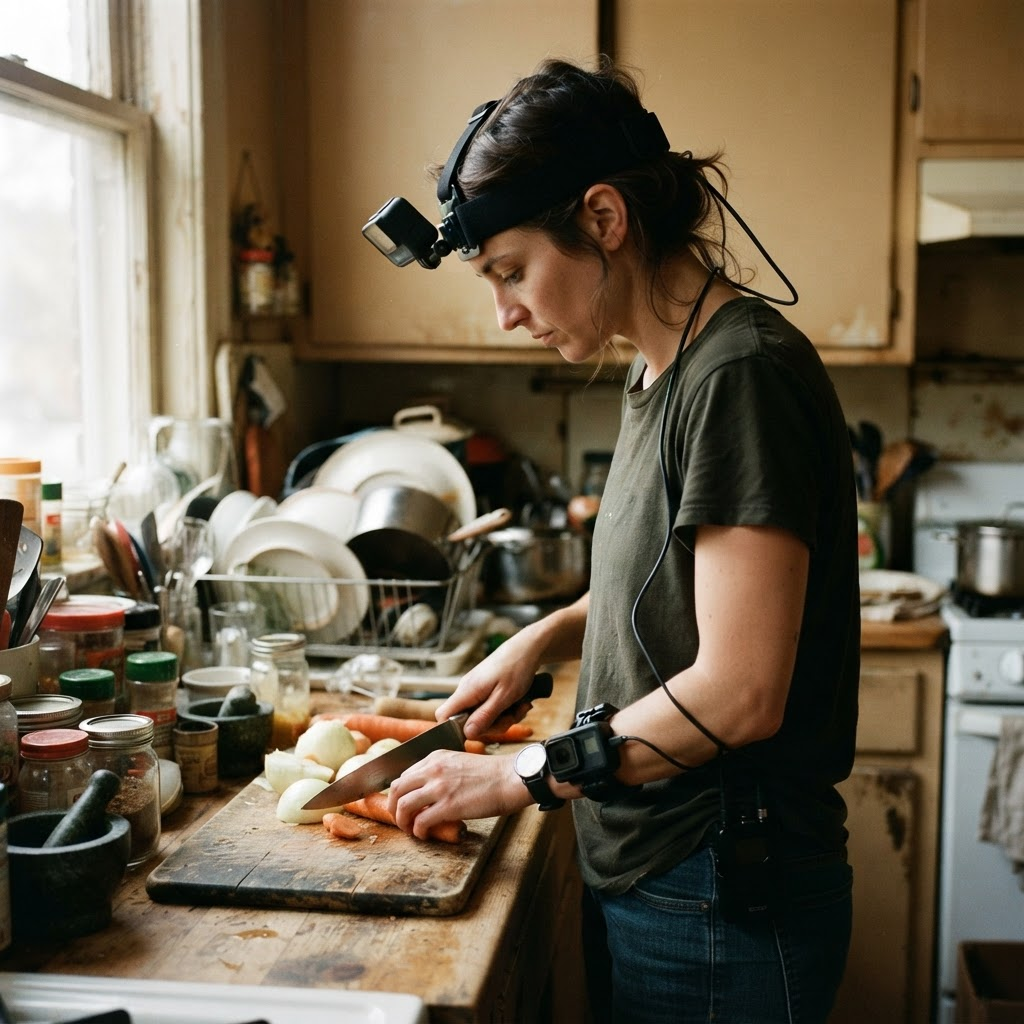
A contributor wearing the Firsthand egocentric capture rig while performing a hands-on task.
Human demonstrations captured from the viewpoint an embodied agent will act from.

Definition

What is embodied AI data collection?

Embodied AI data collection is recording people performing physical tasks from their own point of view, with synchronized video, depth, motion, and hand pose, so models that act in the world can learn manipulation, navigation, and task structure from human demonstration.

How it works

What an embodied AI collection includes.

01

Tasks scoped to your policy

We write the task list, success criteria, and environment mix with you, so demonstrations match the skills you are training rather than whatever was easy to film.

02

Every stream on one clock

Head-mounted and wrist video, depth, IMU, and audio are hardware-synchronized so actions line up with what the camera saw to the frame.

03

Manipulation-grade labels

3D hand joints, action segments, grasp and contact events, and object masks are annotated to the depth your loss function needs.

04

Diversity on purpose

Activities, environments, and regions are balanced across 150+ countries, so a policy does not quietly overfit to one kitchen.

At a glance

What you get.

Streams
Egocentric · wrist · depth · IMU · audio
Labels
3D hand pose · actions · contacts · masks
Spec to first batch
a median of 48 hours (deep coverage)
Formats
RLDS · LeRobot · WebDataset · HDF5
License
Perpetual, buyer-owned

Every collection runs through the same seven-stage end-to-end custom collection pipeline. End-to-end custom data collection is a managed service that takes an AI data need from problem to owned dataset in a single accountable pipeline.

FAQ

Embodied AI data collection, answered.

How much embodied AI data do I need?
It depends on the task breadth and the policy. Most teams start with a focused pilot of a few task families, measure transfer on their own eval, and scale the cells that move it.
Is human egocentric data useful for robots?
Yes. First-person demonstrations teach task structure, hand-object interaction, and visual grounding that transfer to robot policies, especially when hand pose and contacts are labelled.
Can you collect in specific homes or workplaces?
Yes. Environment type, region, and conditions are part of the spec. Thin environments get an honest staffing timeline up front.

Brief the gap. Get data back fast.

Tell us what your model is missing. We will quote reach, timeline, and price against a written spec, with a first validated batch in a median of 48 hours where coverage is deep.