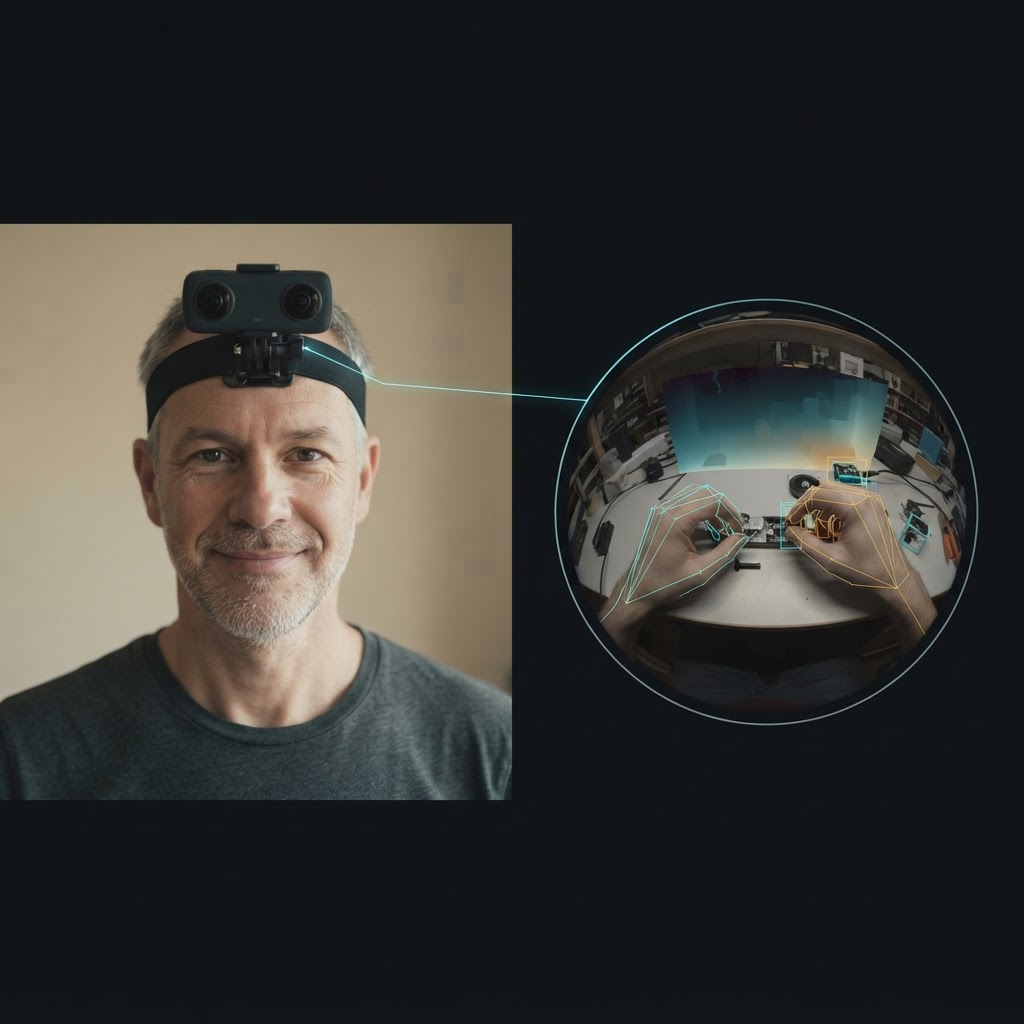
- What is custom training data for humanoid robots?
- It is real-world, first-person human demonstration data captured against a written spec matched to a humanoid's embodiment: head camera viewpoint, two hands in frame, and whole-body motion. Firsthand handles contributors, capture, QA, consent, and delivery.
- Why not use existing robot manipulation datasets instead?
- Most existing datasets were scoped for a specific single-arm or third-person setup, not a humanoid embodiment. A custom collection is specified to your head camera and bimanual configuration and licensed to you, rather than shared across every buyer of an off-the-shelf set.
- Does capture include whole-body pose, not just hands?
- Yes. Each episode includes IMU and 3D body pose alongside 3D hand pose for both hands, so balance and locomotion context are recorded with the manipulation.
- How is custom humanoid data billed?
- Per validated hour, quoted against the written spec before any capture. You pay only for data that clears the accept criteria, and rejected items are recaptured at our cost.
- Which delivery formats are supported?
- RLDS, LeRobot, and WebDataset, plus HDF5, zarr, and Rerun .rrd. Converter source is readable, so you can retarget the schema to your own loader.
- Can we start with a small pilot?
- Yes. A Spec Pilot is a small, fast first batch that proves the spec and accept criteria before you scale volume on demand.