A named brake task list
Replacing pads with a jack, lug wrench and C-clamp, and replacing pads and rotors with a socket set and torque wrench, are different sequences. A spec names each one rather than relying on one generic brake label.
Now recruiting capture teams worldwide. Get paid to record first-person video of real work.
Apply to captureTask family
Requirements
Replacing pads with a jack, lug wrench and C-clamp, and replacing pads and rotors with a socket set and torque wrench, are different sequences. A spec names each one rather than relying on one generic brake label.
Brake work is a chain of lift, remove, compress, fit and fasten. A head-mounted view keeps both hands, the wheel hub and the tools visible through the whole sequence.
3D hand pose with a visibility flag per joint carries the finger detail of holding a clamp, seating a pad and turning a socket, which RGB video alone cannot resolve.
Frame-accurate action segments mark where jacking ends and wheel removal begins, aligned to video and depth on one hardware clock, so a policy can learn the order of the steps.
A perpetual, buyer-owned commercial license backed by a documented consent chain, so a policy trained on the data can go into a product.
Why it matters
Egocentric brake pad and rotor service data is real-world, first-person video of a person doing brake work: jacking the car, removing the wheel, compressing the caliper, replacing the pads and rotor, and torquing the bolts. It is recorded from the operator viewpoint, with depth, 3D hand pose, contact events and frame-accurate action segments aligned on one hardware clock.
Brake work asks a lot of a manipulation policy because it is a chain of heavy, awkward, multi-step handling with different tools at each stage, not a single grasp. A first-person view keeps the wheel, the caliper and both hands in the same frame, which is the viewpoint a robot arm with a head or wrist camera would act from.
This page treats brake pad and rotor service as a task family in its own right. The vehicle maintenance page covers oil, filter, battery, brake and diagnostic work together, and the tire and wheel page covers tire rows. Here the task centres on the brakes.
Setting
The site states brake service in its task catalog. An environment called Auto Service Center & Tire Shop lists three brake rows: one replacing brake pads with a jack, lug wrench and C-clamp, one replacing and torquing brake pads and rotors with a socket set and a torque wrench, and one named Brake Pad & Rotor Service. Its listed examples include brake work next to oil changes, tire rotation and vehicle diagnostics.
All three rows are rated Hard, and all are recorded with the same capture mode, a head-mounted phone or a multiview rig. Two are Active collection and one is Ready to deploy.
A custom spec is scoped from that vocabulary. You describe the vehicles, tools, stations and sequence your policy needs, and the written spec covers them, with the catalog rows as a starting point rather than a fixed menu.
Pad replacement
One row is described as jacking the car, removing the wheel, compressing the caliper and replacing the brake pads, with a jack, a lug wrench and a C-clamp named as the tools. It is rated Hard and its status is Active collection, so recording is running now and a spec can join an existing capture stream.
The motion is a short chain with a clear order: lift, remove the wheel, compress, replace. Action segments are useful here because the boundaries between those steps are exactly the moments a policy has to sequence correctly. A spec can ask for the whole chain or isolate one step.
The site gives no vehicle type, no brake type and no number of wheels per episode for this row. Which vehicle is used, how an episode starts and ends, and whether it covers one wheel or an axle are agreed in the written spec rather than assumed.
Pads and rotors
A second row is described as removing, replacing and torquing brake pads and rotors using a socket set and a torque wrench. It is rated Hard and its status is Active collection. The catalog gives this row a setting as its description, an automotive repair shop with vehicle lifts, tool chests and dedicated service bays, rather than a list of steps.
A third row, Brake Pad & Rotor Service, is described as lifting the car, removing the wheel and caliper, fitting new pads and a rotor and torquing the bolts. It is rated Hard and its status is Ready to deploy, so contributors and site access are set up and capture starts once a spec is signed.
The site states no torque values, no bolt counts and no tightening sequence for any row. A spec that needs a torque step captured defines it up front.
Not stated
Torque values, vehicle or brake types, lift or tool specifications, throughput, force or tactile data, a task-completion label and any safety, brake-performance or certification claim are not stated anywhere on the site as standard fields. This page makes none of those claims.
If your policy needs any of them, they are defined in the written spec as annotation depth, and the quote covers them before capture begins. The page does not promise them by default.
Environments
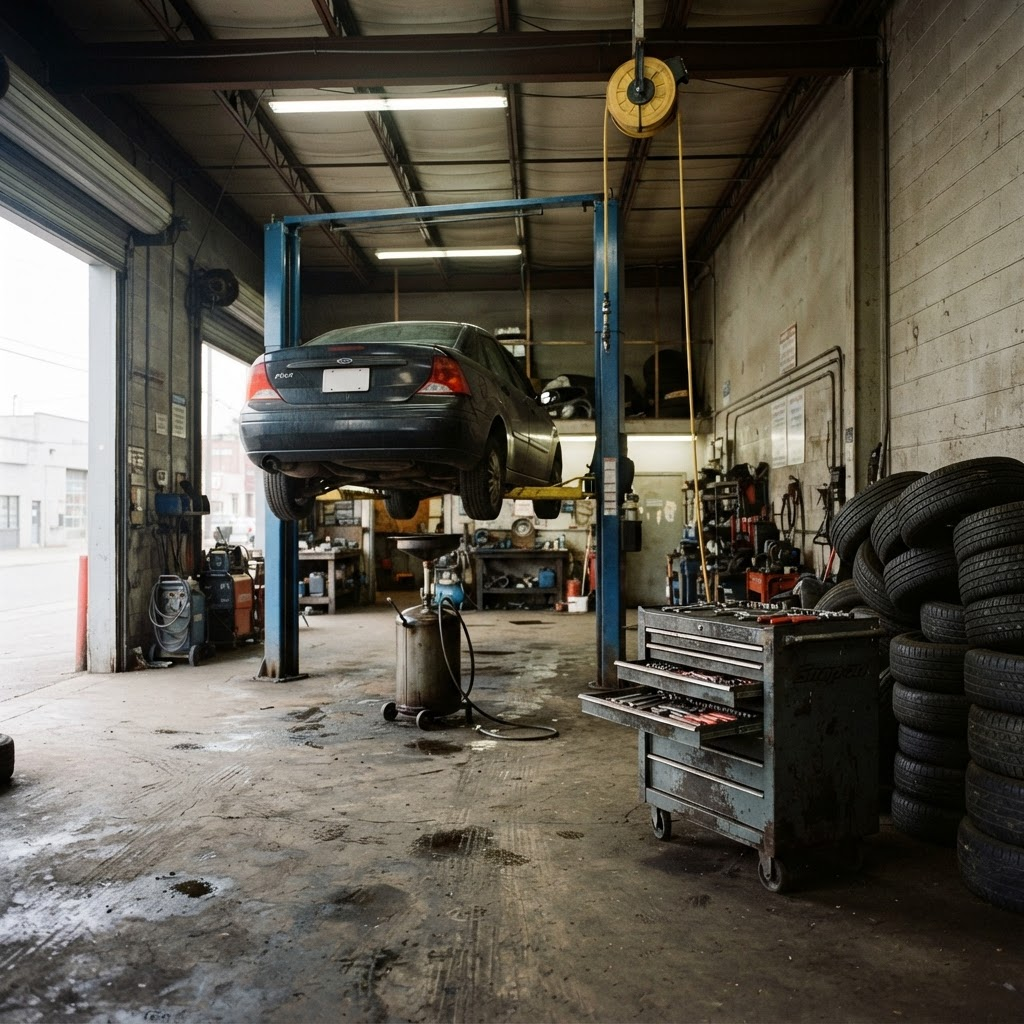
The catalog places the brake rows in its Auto Service Center & Tire Shop environment. The site separately describes its automotive dataset as captured in working service bays rather than a staged mock-up, with a lift bay and under-vehicle work on a lift among the listed bays.
The site defines the statuses plainly. Ready to deploy means contributors and site access are set up and capture starts once a spec is signed. Active collection means recording is running now, so a spec can join an existing capture stream. The brake rows sit in those two, so no brake row is currently scoped-to-spec only.
The site names no shop, dealership, vehicle or brand for any row, and it does not state capture at a customer own facility. Environment, access and schedule are agreed in the written spec.
Capture setup
The catalog names a head-mounted phone or multiview rig as the capture mode for every brake row. A head-mounted phone records the first-person view of real work on site, and a multiview rig adds synchronized third-person angles when the spec asks for them.
A head-mounted camera keeps the lift, remove, compress and fit motion in frame from the viewpoint a manipulation policy will see from, with a wrist-mounted camera available alongside it for close-range detail. Depth, 3D hand pose, contact events and action segments are aligned to video on one hardware clock, synced under 2 ms.
The site does not state a camera count, resolution or frame rate specific to brake service, so those are agreed in the written spec. It also states that the vehicle itself can occlude the view in a service bay, so the second angle from a multiview rig is worth asking for.
Streams and labels
Each episode follows the same episode schema used across Firsthand custom collections: ten streams synced under 2 ms, with head and wrist RGB, depth, 3D hand pose with per-joint visibility, contact and grasp events, and frame-accurate action segments.
For brake service, hand pose tracks the operator through the grip on a clamp or socket, contact events mark when the fingers make and break contact with a wheel, a caliper or a tool, and action segments mark the start and end of each step. Because the labels share one clock with the video and depth, a step boundary lines up with the exact frame where it happens.
Object labels use the terms your spec sets, so labels follow the vocabulary your training stack expects rather than a generic taxonomy.
Depth and light
The site states that the automotive dataset holds a large share of cluttered and low-light work and that under-vehicle capture is hostile to infrared depth, because painted and oily surfaces absorb the projector pattern. Those episodes carry a depth-quality flag instead of being silently interpolated.
Brake work near a lifted vehicle puts the same surfaces in frame, so a spec can ask for the depth-quality flag to be delivered with each episode and for the second angle to cover moments when the vehicle blocks the view. The site does not state a depth accuracy figure specific to brake service.
Delivery
Delivery formats are RLDS, LeRobot and WebDataset, plus HDF5, zarr and Rerun .rrd. The first three are the training-loader formats; HDF5 and zarr carry arrays for custom pipelines, and Rerun .rrd gives a multi-stream synchronized playback file for review. The format table below sets each against what its official documentation states.
Brake episodes use the same schema as every other Firsthand collection, so a loader that already reads another Firsthand dataset reads this one without changes. Every batch is validated against signed accept criteria before it ships, with a reject log, and delivery is rolling, per validated batch.
Privacy
Every episode links to a signed contributor release through a documented consent chain, and the consent record is part of the delivery. Faces, plates and screens are detected and irreversibly blurred at ingest, and a reviewer confirms the result before anything ships.
The site states that licence plates and VIN plates in service-bay footage are blurred at ingest without exception, and the anonymization record is delivered with the data.
Fast · on demand
Where coverage is already deep, the first validated batch lands in a median of 48 hours from signed spec. Thin environments typically take three to four weeks, because vetting operators there is the bottleneck, and we quote that timeline up front. The catalog status on each task row tells you which case you are in, and the brake rows are currently Active collection or Ready to deploy.
On-demand top-ups run against the same spec and accept criteria after each training run, so new brake data stays consistent with what you already hold. The site does not state a batch size or a later-batch turnaround, so those are quoted against your spec.
The spec
You describe the vehicles, tools, stations and sequence your policy needs. We turn that into a written spec covering tasks, environments, capture tier, annotation depth and accept criteria, then quote reach, timeline and price against that document before any capture begins.
A Spec Pilot, a small and fast first batch, can prove the spec and the accept criteria before you scale volume. Billing is per validated hour, a reject log ships with every batch, and rejected items are recaptured at our cost.
Rights
Every custom collection ships under a perpetual, buyer-owned commercial license, and exclusivity is available so the data is never resold. The license is documented alongside the consent chain, so a policy trained on the data can go into a product.
At a glance
Every collection runs through the same seven-stage end-to-end custom collection pipeline. End-to-end custom data collection is a managed service that takes an AI data need from problem to owned dataset in a single accountable pipeline.
What the site states
| Where it appears | What the site states | Used on this page as |
|---|---|---|
| Task catalog, Auto Service Center & Tire Shop | Three brake rows: pads with a jack, lug wrench and C-clamp; pads and rotors with a socket set and a torque wrench; and Brake Pad & Rotor Service | The stated brake service tasks |
| Task catalog, environment examples | Examples read "Car garage, dealership service bay, oil change, tire rotation, brake work, vehicle diagnostics" | Context for the setting |
| Automotive service bay dataset | Working bays listed as lift bay, tyre bay, engine bay work and under-vehicle on lift, with torque wrench to spec on a wheel among its skills | Context for bay setting; brake service is not listed by name |
| Task catalog | No torque values, bolt counts or brake types for any row | Not stated; scoped in the written spec |
Catalog rows
| Catalog task | Catalog description | Skill | Status |
|---|---|---|---|
| Remove and replace brake pads using a jack, lug wrench, and C-clamp | Jack the car, remove the wheel, compress the caliper and replace the brake pads. | Hard | Active collection |
| Remove, replace, and torque brake pads and rotors using a socket set and a torque wrench. | Automotive repair shop with vehicle lifts, tool chests, and dedicated service bays. | Hard | Active collection |
| Brake Pad & Rotor Service | Lift the car, remove the wheel and caliper, fit new pads and rotor and torque the bolts. | Hard | Ready to deploy |
Compared with nearby pages
| Page | Main topic | How brake rows appear |
|---|---|---|
| Egocentric brake pad and rotor service data (this page) | The three brake rows, first-person | The whole page |
| Egocentric vehicle maintenance data | Thirteen rows across oil and fluid, filter, battery, brake and diagnostics work | Three brake rows listed as one of five groups |
| Egocentric tire and wheel service data | Tire dismount and mount, balancing, rotation and dressing rows | Two brake rows named as neighbouring work, with wheel removal as a step |
| Stereo tire and wheel service data | The same five tire rows with a stereo pair and MCAP delivery | Not a brake page |
| Automotive service bay dataset | The existing captured corpus, available under its published terms | Brake service not listed by name |
Capture setup
| Capture mode | What the site says it records | Rows that use it |
|---|---|---|
| Phone (head-mounted) / multiview rig | A head-mounted phone records the first-person view of real work on site; a multiview rig adds synchronized third-person angles when the spec asks for them | Every brake row in the catalog |
| Head-mounted camera | Keeps the lift, remove, compress and fit motion in frame from the viewpoint a manipulation policy acts from | All of the above |
| Wrist-mounted camera | Available alongside the head camera for close-range detail | Stated as an option; per-task use set in the spec |
| Multiview angle | Adds a second view for moments when the vehicle blocks the first-person view | Set in the spec |
Streams and labels
| Item | Status on this site | Why it matters for brake service |
|---|---|---|
| Head and wrist RGB, depth | Stated; ten streams synced under 2 ms | Keeps the wheel, the caliper and the hands on one timeline |
| 3D hand pose with per-joint visibility | Stated | Carries the grip on a clamp or socket and the fit of a pad |
| Contact and grasp events | Stated | Marks when the fingers make and break contact with a wheel or tool |
| Action segments | Stated; frame-accurate | Marks jacking, wheel removal, compressing, fitting and torquing as separate steps |
| Depth-quality flags | Stated for IR-hostile automotive episodes | Flags surfaces that depth sensors find hard |
| Torque values, bolt counts | Not stated | Defined in the spec if the policy needs them |
| Vehicle or brake types | Not stated | Defined in the spec |
| Lift or tool specifications | Not stated | Defined in the spec |
| Throughput, force or tactile data | Not stated | Defined in the spec if the policy needs them |
| Task-completion label, safety or brake-performance claim, certification | Not stated | No such claim is made on this page |
Formats
| Format | What the official documentation states | Used for here |
|---|---|---|
| RLDS | A dataset is retrieved as episodes, and each episode holds a dataset of steps (RLDS repository README) | Episode-based training loaders |
| LeRobot | LeRobotDataset v3.0 is a standardized format for robot learning data, including multi-camera video, with many episodes stored per Parquet or MP4 file (LeRobot documentation) | LeRobot dataset format and tooling |
| WebDataset | Tar files in which files that belong together share a basename, split into numbered shards (WebDataset README) | Sharded streaming for large training runs |
| HDF5 and zarr | Stated by Firsthand only | Array storage for custom pipelines |
| Rerun .rrd | Stated by Firsthand only | Multi-stream synchronized playback for review |
Example footage
Two real clips already published on this site. The first is a household chores clip of an operator carrying a cordless vacuum down a staircase into a living room, a first-person hands-on clip hosted on the site. The second is a format and rig example: a head-mounted stereo capture with hands in frame. Neither shows brake service.
No brake service clip is published on the site, so these are labelled as format and rig examples. Request a sample to see delivered files. See stereo sample page, stereo + wrist-cam example videos, request an egocentric data sample.
FAQ
Sources
Tell us the vehicles, tools, stations and sequence your policy needs to handle. We will quote reach, timeline, and price against a written spec, with a first validated batch in a median of 48 hours where coverage is deep.