Wiping and cleaning

Egocentric Wiping and Surface Cleaning Video Data

Clearing a counter, wiping it down and putting things back sounds routine, and it is the kind of chore a household robot is asked to do all day. We collect custom egocentric video of wiping and surface cleaning on demand, to a written skill spec, with synchronized streams, action segments, anonymization and a buyer-owned license.
Tasks
Wipe, clear and reset surfaces, as the catalog lists them
Streams
Ten, synced under 2 ms
First batch
Median 48 h in deep-coverage settings
License
Perpetual, buyer-owned
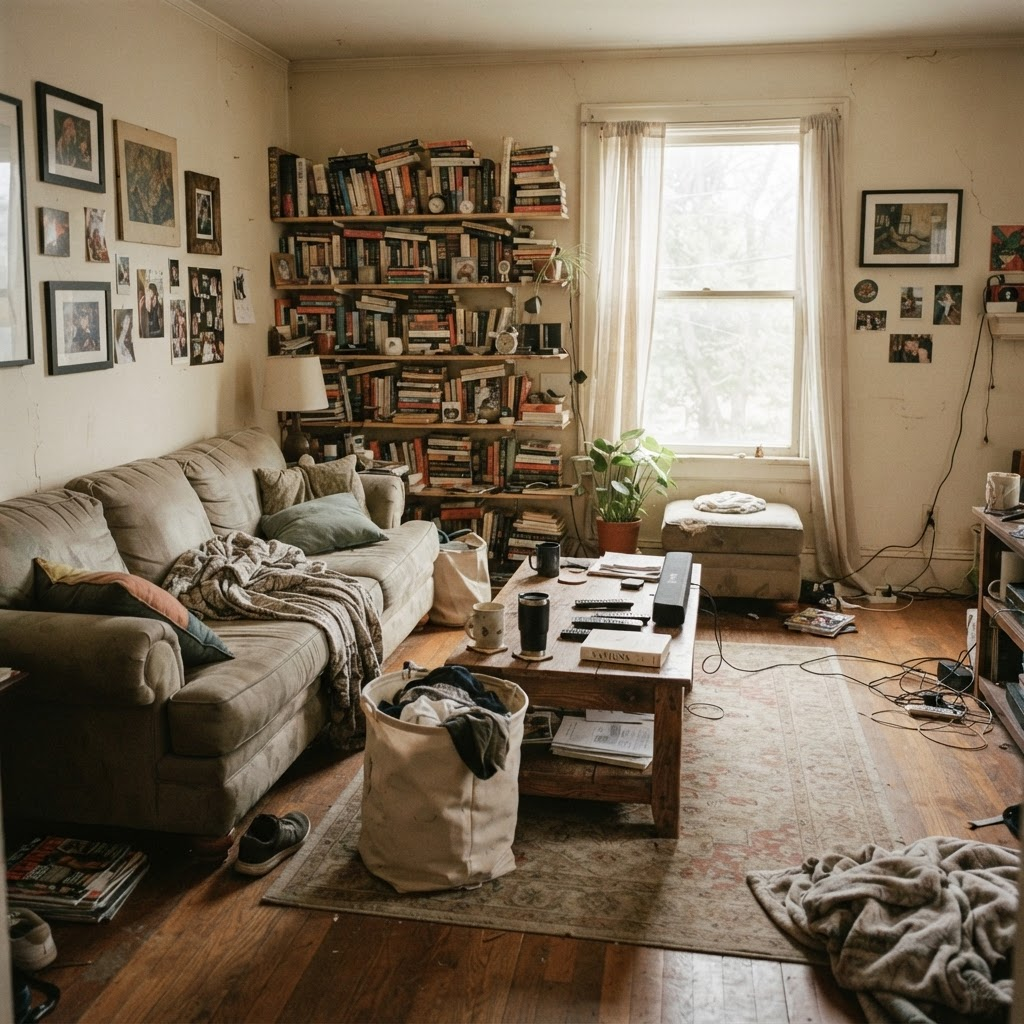
A lived-in living room with a worn sofa, mugs on the coffee table and a laundry basket, seen from a first-person viewpoint.
Head-worn capture keeps the hands, the surface and the cloth in view from the contributor’s own point of view, which is the view a robot working the same room would have.

Requirements

What does wiping capture need that a generic kitchen clip does not?

01

The hand, the cloth and the surface in view together

A wipe is one hand, one cloth and a surface moving against each other. First-person capture keeps the hands and the work area in frame, and 3D hand pose carries a per-joint visibility flag so a finger hidden under a cloth is flagged rather than guessed.

02

A spec that names the step, not just the room

The site’s skill-spec guide says to name the verb and the noun rather than a broad activity. A spec for this family names the surface and the step, such as clearing a counter, wiping it and resetting it, and where one completed step starts and ends, so each can become its own labeled segment.

03

Wet and glossy surfaces handled on purpose

The site states that wet and reflective surfaces degrade active-stereo depth, and that per-frame confidence maps are shipped so you can mask rather than guess. A freshly wiped counter is exactly that case.

04

Reject rules written before capture, not after

An item is rejected when the manipulated object is out of frame for too much of the episode, when depth is invalid over too much of the manipulation region, or when an undocumented bystander appears. The thresholds are agreed in the spec, so the batch is judged against terms you signed.

Definition

What is egocentric wiping and surface cleaning data?

Egocentric wiping and surface cleaning data is first-person video of a person wiping a counter, a table or another surface, clearing it first and resetting it afterwards, recorded from the contributor’s own point of view with synchronized sensor streams alongside. The camera sits on the head, close to what a household robot’s onboard camera would see over a counter or a work surface, so the frames show what the hands and the cloth do rather than a distant view of someone standing near a mess. On this site it is a custom collection: you name the task, the surface, the room and the steps involved, and capture is run to a written skill spec.

The data is human capture. A paid, consented contributor wears the rig and performs the task. It is not robot or teleoperation data, and it is not a fixed corpus you download. This page is narrower than household robot pretraining data, which spans laundry, tidying, cleaning and surface reset across homes, narrower than dishwashing data, which centres on washing, racking and putting away dishes, and narrower than table setting and clearing, which centres on the table. The subject here is the wipe-and-clean-a-surface family of tasks and what the site states about capturing, labeling and checking them.

People reach this topic through close cousins: wiping robot training data, a surface cleaning video dataset, egocentric cleaning task data, or custom household cleaning data collection. They describe one request from different angles, and the work is the same: write down the task, collect it on demand from real counters and rooms, and receive validated episodes. Nothing on this page states that the video carries a cleanliness score, a coverage map or a contact-force reading.

Why it matters

Why do robots need first-person video of wiping and cleaning surfaces?

NVIDIA’s GR00T N1 paper describes a data pyramid with web data and human video at the base, synthetic data in the middle and real robot trajectories at the top. First-person human video of wiping and cleaning work sits in that base layer. Human capture does not replace robot data, and this page does not claim that it does.

Wiping looks simple, and a clip that shows a hand somewhere near a counter does not carry what a policy needs. The hand, the cloth, the surface and the moment of contact all have to be present in the episode, and the episode has to say where one step ends and the next begins. That is the difference between footage of someone cleaning and an episode a model can learn a step from.

The site already names this family in several places. Its household chores dataset lists surface wipe and clutter reset among its skills, and describes laundry, tidying, cleaning and surface reset across whole homes. Its kitchen dataset lists wiping and resetting a work surface. Its household pretraining page describes the same cleaning and surface reset work, and the commercial task catalog lists wipe rows across many settings. This page takes that slice and gives it a dedicated spec, so you can ask for the steps your model is missing instead of hoping a broad household collection happens to contain them.

Breadth across surfaces and rooms matters as much as volume on one of them. Generalist’s GEN-0 write-up makes a point about data in different words: "data quality and diversity matters more than sheer volume." For wiping that points at the spread of surfaces, rooms and clutter. The kitchen dataset lists clutter among its conditions, with counters left as found rather than staged, and a counter wiped at the end of a meal looks different from a table cleared in a hotel service set. A corpus that repeats one counter does not cover that spread.

A custom collection lets you aim at the surface, the step and the setting your model is missing. This page does not claim that any particular public corpus lacks wiping or cleaning work.

Wiping and cleaning tasks

Which wiping and cleaning tasks can be captured?

The first table below reproduces twelve rows of the site’s commercial task catalog that name a wipe or a surface-cleaning step. Each is listed with a skill level, a capture setup and a status exactly as the catalog states them. It is a selection, not the whole catalog. Other rows, such as bathroom and restroom sanitizing with sprayers and mops, kennel cleaning, workshop dust wipe-downs and sand-and-wipe rows, also mention wiping or cleaning, and they are left out because the wipe is one part of a wider task or because they sit in settings this page does not cover.

The three counter and table rows come from the kitchen and hospitality service sets. The catalog lists wipe counter and trash, which is clearing a counter, wiping it and bagging trash, wipe and reset a counter, and clear and bus a table, which is stacking dishes, busing and wiping. All three are listed as easy, use a multiview rig with handheld grippers, and are marked available on request. Banquet plating is a different task that includes wiping plate rims, listed as medium.

The catalog also lists wiping inside other settings. Bathroom cleaning at a hotel, which includes wiping mirrors and surfaces, is marked ready to deploy, and surface sanitizing, which sprays and wipes desks, handles and high-touch surfaces, is marked active collection. Care room, hospital, dental clinic, hair salon, veterinary clinic and gym rows each include a wipe-down step and are marked available on request or active collection as the table shows. These are catalog listings, and the page does not claim more about them than the catalog does. They do show that surfaces, rooms and the cloth-and-spray steps vary a great deal.

The second table shows where the site itself names wiping: the household chores dataset, the kitchen dataset, the in-home and household pretraining pages, and the catalog. It is there so you can see which statements are about homes and which are about other settings, because the catalog rows above are mostly commercial, hospitality and clinical rather than domestic.

No catalog row is titled spill cleanup, and the site does not describe a cloth type, a sponge, a surface material, a stain type or an area size for any of these rows, so none is stated here. A surface, stain, spill or setting outside these rows is a skill-spec question to settle in a Spec Pilot rather than an assumption. The catalog is a list of what is captured or available, not a ceiling on what can be briefed.

Capture setup

What capture setup and streams are used?

A wiping collection uses the same capture stack as every Firsthand program. The instrumented tier is a head-mounted stereo rig that records first-person RGB, with a metric depth stream recovered from the calibrated stereo rig rather than from a standalone depth sensor, and 6-DoF IMU data at 200 Hz from head- and wrist-mounted sensors. The wider stack is ten streams: a 4K head camera, two wrist cameras, depth, IMU, 3D hand and body pose, instance segmentation and action labels, hardware-aligned under 2 ms. The two wrist cameras give a second, closer view of the hands than the head camera alone, which matters when a hand presses a cloth flat or reaches into a corner.

Every stream is hardware-triggered onto one PTP clock domain, so depth, motion and hand pose line up with the same video frame rather than being approximated afterwards. The rig is calibrated twice per session, before capture starts and after it ends, and an episode is accepted only if RMS reprojection stays under 0.28 px. The catalog lists the capture setup per task: a multiview rig with handheld grippers for the counter, table and care-room rows, and a head-mounted phone or multiview rig for the bathroom, facility, clinic, salon, gym and banquet rows. Which tier applies to your program is set in the skill spec.

On depth, the site states that wet and reflective surfaces degrade active-stereo depth, which is why per-frame confidence maps are shipped so you can mask rather than guess. A wiped counter is wet and glossy for a moment, so that statement applies directly. The site does not state how much depth is lost on a particular surface, a cloth or a film of water, and it does not state a camera count, resolution or frame rate specific to wiping. Force and tactile readings are not among the streams, and no robot or teleoperation data is captured.

Labels

Which labels and annotations are available?

Each attempt is delivered as one episode. Inside it, action segments divide the episode into start- and end-timestamped spans, each carrying start_ns, end_ns, verb and noun. For this task family a segment can be one step as written in the skill spec, so a counter reset becomes a sequence of labeled steps such as clear, wipe and put back rather than one long clip. The other standard fields are hand_joints and hand_visible for 3D hand pose, contact_events for the moment the hand meets an object, objects, and instance_masks, stored at the depth resolution of 848×480 so they line up with the depth stream.

Hand pose is delivered for both hands with a per-joint visibility flag for occluded fingers. That is the label that carries the two-handed structure of wiping: where one hand steadies or lifts an item while the other works the cloth. Action segments mark where one step ends and the next begins. The site describes contact events as the moment the hand meets the item, and does not say whether a cloth or the surface itself counts as the item, so the spec is the place to settle what a contact event means for your task.

Masks need a spec decision. The site states that clothing, bedding and bags do not track well with masks propagated frame to frame, so deformable captures ship per-frame instance masks where the spec calls for them. Cloths, sponges and rags are not named in that statement. Whether a wiping cloth needs per-frame masks is settled in the spec rather than assumed.

The site does not list labels for how clean a surface became or how the cloth moved. There is no stated label for a coverage map, a cleanliness score, a stain or residue annotation, a wipe pattern, a contact force or pressure reading, or a task-completion score. Several catalog task descriptions mention checking, disinfecting or resetting, but that describes the task the contributor performs, not a delivered measurement.

Stated limits

What does the site state about the hard parts of recording wiping work?

Several limits the site already states apply directly to wiping capture, and several it leaves open. Each stated limit below appears elsewhere on the site rather than being introduced here.

Hand occlusion is the first. Fingers disappear behind objects in manipulation, which is why 3D hand pose carries a per-joint visibility flag. A hand pressed flat under a cloth is an everyday case here. The second is wet and reflective surfaces, which degrade active-stereo depth and are the reason confidence maps ship. The third is masks, where per-frame instance masks are the stated answer for items that do not track well when propagated, and the spec is where you decide whether a cloth needs them.

The fourth is the set of machine-checked reject criteria. An episode is rejected for a sync breach beyond the ceiling for more than three consecutive frames, calibration drift beyond tolerance, the manipulated object out of frame for more than 15 percent of the episode, more than 35 percent invalid depth pixels in the manipulation region, an undocumented bystander, or a mismatch against the named skill spec. A human reviewer then checks each episode against the task spec.

The kitchen dataset also names the conditions that stress a household capture: clutter, with counters left as found, and failure cases such as drops, spills, mis-grasps and recoveries. Those are listed as conditions of that dataset, and spills there are a failure case rather than a cleanup task. What the site does not state is just as useful to know before you scope. It gives no mask accuracy figure for cloths, no description of how glare on a clean counter or steam above a wet one is handled for wiping, and no cleanliness or coverage annotation. If your policy depends on any of those, say so at the start.

QA, consent and safety

How do QA, consent, safety and anonymization apply in homes?

Validation runs against signed accept criteria written into the spec before capture. Each batch goes through per-batch QA and a reject log ships with it. Only footage that clears the criteria is billed as a validated hour, and rejected items are recaptured at our cost. Many teams start with a Spec Pilot, a small, fast first batch that proves the spec and the accept criteria on real footage before volume scales.

Every contributor signs a written release before capture, and each delivered episode links to that record through consent artefact IDs in the batch data card. The consent chain has six checkpoints, from before capture to after delivery, and a break at any one discards the footage rather than shipping it at a lower grade. At ingest, automated detection finds faces, plates and screens and blurs them irreversibly, and speech is scrubbed of names, addresses and card numbers while ambient audio is kept. A human reviewer confirms that no un-consented person is identifiable in any frame, and footage that cannot be de-identified is discarded. The anonymization record is delivered with the data.

Homes add their own conditions. The site states that household capture happens inside lived-in spaces, that bystanders are de-identified or the footage is discarded, and that bathroom capture excludes any episode with a person in frame other than the consenting operator. A counter in a home can carry mail, papers or other printed items. The site states that mail and barcodes are not listed as blur categories, so this page does not claim they are blurred. The listed categories are faces, plates and screens. If text on items in frame matters for your use, raise it in the spec so the handling is agreed before capture rather than assumed afterwards.

On safety and qualification, the site states no contributor safety protocol, no chemical-safety guidance and no safety certification for any wiping or cleaning row, and this page does not describe one. If your program needs terms about who performs the work, the products used or the conditions under which it is done, raise them when you scope it. None of this is legal advice, and the executed agreement controls.

Delivery and speed

How fast can a custom wiping and cleaning dataset be delivered?

From signed spec to first validated batch, the timeline is a median of 48 hours where coverage is deep and three to four weeks where it is thin and contributors need to be recruited first. Speed comes from a warm pipeline, not from cutting consent, review or anonymization. After the first batch, on-demand top-ups run against the same accept criteria, so you can add more surfaces, rooms or variation without rewriting the spec. The site does not state a turnaround for those later batches, so plan them in your quote.

Delivery is in the format your stack already reads: RLDS, LeRobot, WebDataset, HDF5, zarr or Rerun .rrd, or raw streams with metadata. Readable converter source ships alongside the data so the schema can be retargeted to your own loader. Collections are billed per validated hour.

The license is perpetual, irrevocable and worldwide, with the data buyer-owned and non-exclusive by default. Training, evaluating, fine-tuning and deploying models, including commercial ones, is permitted, and exclusivity is available as a separate term. The executed agreement controls. The site does not publish a price list, a minimum order or a batch size for this task family, so those are set in your quote.

Not stated

What does a wiping and cleaning collection not include?

Where this site does not state something, this page says "not stated" rather than filling the gap. The table below separates what is delivered from what is not stated. There is no listed label for coverage, cleanliness, stains or wipe pattern, no force or tactile stream, no cloth, surface or product specification, and no area size. Nothing here claims a training outcome or a model improvement.

The tradeoff to plan for is the embodiment gap between a human hand and a robot end-effector, which retargeting or pairing with robot data has to close. Counts of homes, contributors, hours and tasks are set in your skill spec.

Getting started

How do you scope and request a custom wiping and cleaning dataset?

Describe the surfaces, the steps, the rooms and the variation or failure cases your pipeline is missing. That becomes a written skill spec, quoted for reach, timeline and price before any capture begins, and most programs run a Spec Pilot first. The scoping checklist below maps the parts of a skill spec onto a wiping request. A published sample recording is on the sample data outputs page if you want to see the streams before you write a spec.

Three choices matter most for this family. Name the step and the surface rather than a broad activity, because that is what lets each step become one action segment. Name the setting and the capture tier, since a home counter, a hotel bathroom and a clinic room present different geometry and the catalog lists a different capture setup for them. And name the lighting and participant mix: daylight coverage fills fastest, while evening, low-light capture is the harder cell to fill.

Capture setup

What is the capture setup for a wiping and cleaning collection?

The capture setup as stated on this site, applied to wiping and cleaning work. Counts of homes, contributors and hours are set in the skill spec.
PartAs stated on this site
Instrumented rigHead-mounted stereo rig worn by the contributor; first-person RGB
StreamsTen: 4K head camera, two wrist cameras, depth, IMU, 3D hand and body pose, instance segmentation, action labels
SyncHardware-triggered onto one PTP clock domain; aligned under 2 ms
DepthMetric depth recovered from the calibrated stereo rig; wet and reflective surfaces degrade active-stereo depth, so per-frame confidence maps are shipped
IMU6-DoF at 200 Hz from head- and wrist-mounted sensors
CalibrationTwice per session; accepted only under the 0.28 px RMS reprojection gate
MasksPer-frame instance masks where the spec calls for them, stored at 848×480
Catalog capture setupMultiview rig with handheld grippers for counter, table and care-room rows; head-mounted phone or multiview rig for bathroom, facility, clinic, salon, gym and banquet rows

Every collection runs through the same seven-stage end-to-end custom collection pipeline.

Task variations

Which wiping and cleaning tasks does the catalog name, and what is captured?

Twelve catalog rows that name a wipe or surface-cleaning step, reproduced as the catalog states them. The selection is not the whole catalog, and most rows are commercial, hospitality or clinical rather than domestic.
Task (as listed)Description (as listed)EnvironmentSkill levelCapture setupStatus
Wipe counter + trashClear, wipe a counter, and bag trash.Working Kitchen Set (food prep)EasyMultiview rig + handheld grippersAvailable on request
Wipe + reset counterClear, wipe, and reset a counter.Hospitality Service Set (table, bar, room)EasyMultiview rig + handheld grippersAvailable on request
Clear + bus tableStack dishes, bus, and wipe.Hospitality Service Set (table, bar, room)EasyMultiview rig + handheld grippersAvailable on request
Banquet platingPortion hot dishes onto plates in sequence, wipe rims and load plates onto service trays.Catering & Event KitchenMediumPhone (head-mounted) / multiview rigAvailable on request
Bathroom cleaningScrub the toilet, sink and shower, wipe mirrors and surfaces and replace towels.Hotel & LodgingEasyPhone (head-mounted) / multiview rigReady to deploy
Surface sanitizingSpray and wipe desks, handles and high-touch surfaces with sanitizer.Commercial Cleaning & JanitorialEasyPhone (head-mounted) / multiview rigActive collection
Wipe + clean surfacesWipe down surfaces and rails.Care Room (assistive care)EasyMultiview rig + handheld grippersAvailable on request
Surface decontaminationWipe down beds, rails and equipment with disinfectant and dispose of used wipes.Hospital & Clinical CareEasyPhone (head-mounted) / multiview rigAvailable on request
Post-procedure cleaningClear the tray, dispose of sharps and waste, wipe and disinfect the chair and surfaces.Dental ClinicEasyPhone (head-mounted) / multiview rigAvailable on request
Workspace sanitationSweep hair, disinfect tools and chairs and wipe down the station between clients.Hair Salon, Barbershop & Beauty StudioEasyPhone (head-mounted) / multiview rigActive collection
Examination room prepWipe the table, lay out instruments and supplies and set up the room for the next patient.Veterinary ClinicEasyPhone (head-mounted) / multiview rigAvailable on request
Floor cleaningMop and disinfect gym floors and mats and wipe down equipment.Gym & Fitness StudioEasyPhone (head-mounted) / multiview rigAvailable on request

Where wiping is named

Where does the site name wiping or surface cleaning, and in what words?

Each statement is quoted or closely paraphrased from a page on this site. Only some of them concern homes.
WhereWording on the siteWhat it tells you
Household chores datasetSkill: "Surface wipe and clutter reset"; laundry, tidying, cleaning and surface reset across whole homesThe household wipe task and the home setting
Kitchen datasetSkill: "Wipe and reset a work surface"; counters left as found, not stagedA kitchen wipe task captured in unstaged conditions
In-home data collection pageLaundry, tidying, cleaning and surface reset, as listed in the household chores datasetWiping falls inside the stated in-home task set
Household robot pretraining pageLaundry, tidying, cleaning and surface resetWiping as part of a broad household corpus
Commercial task catalogTwelve selected rows above, with skill level, capture setup and statusSurface wiping across counter, hospitality, facility and clinical settings
Spill cleanup, cloth or product typeNot statedSettled in the skill spec

Streams and labels

Which streams and labels are delivered for wiping work, and which are not stated?

Delivered items are stated elsewhere on this site. Items marked not stated are not promised on this page.
Stream or labelWhat it gives a wiping episodeStatus
Head and wrist camerasFirst-person view of the task plus a closer view of the handsDelivered
Depth with confidence mapsSurface geometry; wet and reflective surfaces degrade active-stereo depth, so confidence maps shipDelivered
6-DoF IMU at 200 HzHead and wrist motion aligned to the video frameDelivered
3D hand pose with per-joint visibility flagsBoth hands across the step; occluded fingers flaggedDelivered
Contact eventsThe moment the hand meets an itemDelivered
Action segments (start_ns, end_ns, verb, noun)One labeled span per stepDelivered
Per-frame instance masks (848×480)Item masks where the spec calls for themDelivered where specified
Consent artefact IDs and anonymization recordProvenance per episodeDelivered
Coverage map or cleanliness scoreNot listedNot stated
Stain, residue or wipe-pattern annotationNot listedNot stated
Contact force or pressureNot among the listed streamsNot stated
Spill-cleanup task labelSpills are named as a failure case in the kitchen dataset, not as a cleanup taskNot stated
Force or tactile readingsNot among the listed streamsNot stated
Robot or teleoperation dataHuman first-person demonstrations onlyNot captured
Counts of homes, contributors, hours and tasksSet per program in the skill specNot stated

Scoping checklist

What does a wiping request put into each part of a skill spec?

The parts of a skill spec as the site’s guide describes them, applied to a wiping request. The catalog wording is quoted where it helps; your own fields and numbers are agreed with you.
Skill-spec partWhat to name for a wiping requestDrawn from what the site states
Named skillThe verb and the noun: the clear, wipe or reset step and the surface, not "cleaning"Catalog wording such as "Clear, wipe, and reset a counter."
Geometry that must be visibleWhat must be in frame and for how long: both hands, the cloth, the surfaceSet in the skill spec
Condition budget in hoursHours per condition cell, including clutter, failure cases and the roomsSet per program in the skill spec
Reject ruleThe conditions that fail an item, written firstObject out of frame for more than 15 percent of the episode; more than 35 percent invalid depth pixels in the manipulation region; an undocumented bystander
Acceptance testOne test that decides whether an attempt counts as completeYour acceptance test is agreed in the spec
Setting and capture tierHome counter, hotel bathroom, clinic room or care room, and phone or multiview rigThe catalog lists a capture setup per row
Wet surfaces and text in frameWhether wet glare and printed items on the surface need special handlingConfidence maps ship for wet surfaces; mail is not listed as a blur category
Participants and lightingHandedness, technique and pace; daylight or low lightSet per program in the skill spec

FAQ

Egocentric wiping and surface cleaning video data, answered.

What is egocentric wiping and surface cleaning video data?
Custom first-person video of people wiping counters, tables and other surfaces, clearing them first and resetting them after, captured by paid, consented contributors wearing a capture rig and doing the tasks in a written skill spec, and delivered with synchronized streams, hand pose, action segments and consent and anonymization records.
Which wiping and cleaning tasks does Firsthand capture?
The household chores dataset lists surface wipe and clutter reset, and the kitchen dataset lists wiping and resetting a work surface. The task catalog names wiping a counter, resetting a counter, clearing and wiping a table, and wipe-downs in hospitality, facility and clinical settings. Anything else is settled in the skill spec and a Spec Pilot.
What streams and labels come with a wiping episode?
Ten hardware-synchronized streams, including head and wrist cameras, depth with confidence maps, IMU, 3D hand pose and instance segmentation, plus action segments with start_ns, end_ns, verb and noun, hand pose with visibility flags and contact events.
Do you provide coverage, cleanliness or contact-force labels?
Not stated. The delivered fields are action segments, 3D hand pose with visibility flags, contact events, objects and instance masks where the spec calls for them. No coverage map, cleanliness score, stain annotation, wipe pattern, contact force or pressure reading is listed, and force and tactile readings are not among the streams.
How does depth cope with a wet or glossy counter?
The site states that wet and reflective surfaces degrade active-stereo depth, and that per-frame confidence maps are shipped so you can mask rather than guess. It does not state how much depth is lost on a particular surface.
Is capture done inside real homes, and how is privacy handled?
Household capture happens inside lived-in spaces, with a signed release per contributor, de-identification of bystanders or discarding of the footage, and bathroom capture excluding any person in frame other than the consenting operator. Faces, plates and screens are blurred irreversibly and reviewer-confirmed. Mail and barcodes are not listed as blur categories, so agree the handling in the spec.
How fast can a custom wiping and cleaning dataset arrive?
A median of 48 hours from signed spec to first validated batch where coverage is deep, and three to four weeks where it is thin. The site does not state a turnaround for later top-up batches.
Who owns the data, and what formats are offered?
The buyer owns the delivered data under a perpetual, irrevocable, worldwide, non-exclusive commercial license by default, with exclusivity available as a separate term. Delivery is in RLDS, LeRobot, WebDataset, HDF5, zarr or Rerun .rrd, or raw streams with metadata.
Sources

Where are these wiping and cleaning capture claims documented?

Request a custom wiping and cleaning dataset.

Tell us the surfaces, the steps and the rooms your model needs to see. We will quote reach, timeline and price against a written spec, with a first validated batch in a median of 48 hours where coverage is deep.