Procedural tasks

Procedural Task Video Data Collection

A procedure is a task done in a fixed or partly fixed order of steps — assemble, then fasten, then inspect; mix, then portion, then package. Training a robot or AI system on that kind of work means capturing not just that a task happened, but how its steps are ordered, where each one starts and ends, and what it looks like when a step is skipped, repeated, or corrected. We capture that procedural task video data on demand, to a written spec, with the same consent, QA, and licensing process used across every custom collection on this site.
Core unit
A named procedure broken into ordered steps
Streams
Head/wrist RGB, hand pose, action segments, as specced
First batch
Median 48 h in deep-coverage settings
License
Perpetual, buyer-owned
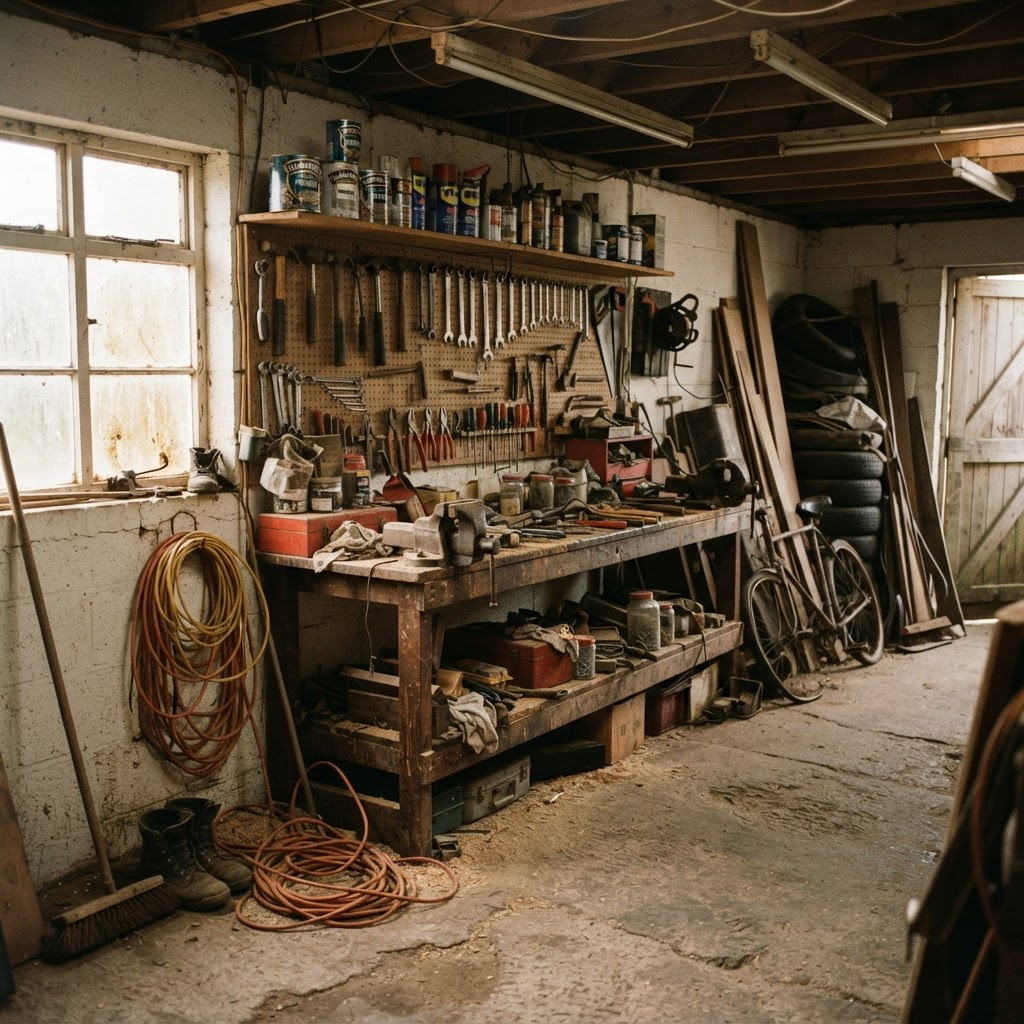
A first-person view of a multi-step bench task, representative of the ordered, step-by-step work captured for procedural task video data.
A procedure’s value is in its step order and boundaries, not just the fact that the task was completed.

Requirements

What does procedural data need that single-action capture does not?

01

Step order is part of the signal, not just the outcome

A procedure is defined by its sequence — step two cannot happen before step one, and some steps depend on an earlier one finishing correctly. A spec for procedural data has to name that order explicitly, so the labeled action segments carry step sequence, not only a list of actions that happened somewhere in the clip.

02

Step boundaries have to be drawn consistently

Where one step ends and the next begins is not always obvious from raw video — a pause, a tool switch, or a shift in hand position can mark a boundary. Action segments mark the start and end of each discrete step so that boundary is explicit in the delivered data rather than left for a model to infer from an unlabeled clip.

03

Skipped, repeated, and corrected steps are real cases, not noise

A procedure performed by a real person sometimes skips a step, repeats one, or redoes it after a mistake. Representing those variations — not only the clean, every-step-in-order version — is part of what a written spec can call out as a requirement for a batch, alongside failure and recovery labeling.

04

Consistency across contributors and batches

If a procedure is captured from multiple contributors or across multiple batches, the step definitions and boundaries need to stay consistent so the labeled data can be combined into one training set rather than several incompatible ones.

Definition

What is procedural task video data?

Procedural task video data is first-person video of a task performed in a fixed or partly fixed order of steps — recorded from a camera positioned near the worker’s own point of view, a chest mount, head rig, or wrist camera, rather than a fixed overhead or side-angle camera. What distinguishes it from other egocentric task data is the step structure: the procedure is decomposed into named steps with their own boundaries, rather than treated as one undifferentiated action.

The underlying capture, labeling, QA, and licensing process is the same one used across every custom collection on this site: a written skill spec describing the procedure and its steps, paid and consented contributors performing the real task, synchronized sensor streams recorded alongside the video, and per-batch QA before delivery. What changes for procedural data is the emphasis on step order and boundaries in both the spec and the labeling pass.

Fit

Which procedures are a good fit for custom capture?

A good fit is any task performed the same way, in roughly the same order, many times — an assembly sequence, a multi-step prep or build process, a fixed inspection routine, a setup-then-operate-then-shutdown cycle. Each breaks down into specific, nameable steps, which is what a written skill spec is built to describe.

Procedures with a partly fixed order — where some steps can happen in either sequence but others cannot — are also a reasonable fit, as long as the spec states which steps are strictly ordered and which are flexible. A task with no meaningful step structure at all is usually a better fit for this site’s general action-labeled or task-decomposition pages than for a procedural-specific program.

This page is about procedure structure specifically — step order, boundaries, variation, and completion — rather than about an enterprise SOP program, pretraining-scale diversity, or a specific label-format question. For those angles, see this site’s enterprise workflow data and action-labeled egocentric video pages.

From procedure to spec

How is a procedure written into a skill spec?

A procedural collection starts the same way any custom collection on this site does: you describe the procedure your training pipeline needs covered — what the steps are, what order they happen in, which steps are strictly sequential versus flexible, and which failure or skipped-step cases need to be represented. That becomes a written skill spec naming the step list and order, the setting, the participant mix, capture tier, annotation depth, and accept criteria, quoted for reach, timeline, and price before any capture begins.

This is the same task decomposition process used across the site: a procedure is broken into named task units with a clear start, end, outcome, and object set, each further divided into labeled action segments. The difference with a procedural spec is that the order between those units is itself part of what gets written down and labeled, not just the units themselves.

Many programs start with a Spec Pilot, a small, fast first batch that proves the spec and accept criteria on a limited step set before scaling to full volume. That lets a buyer confirm step boundaries and label quality on part of a procedure before committing to capture across the full sequence.

Labeling

How are step boundaries and step order labeled?

Raw video alone does not tell a model where one step ends and the next begins, which is why captured footage is broken into the same structure used across every collection on this site: action segments marking the start and end of each discrete step, and episodes grouping a full procedure attempt from start to finish. For a procedure, those action segments are ordered to reflect the sequence named in the spec, so step order is explicit in the delivered labels rather than left implicit in the raw clip.

An assembly procedure, for example, segments into its component steps — position the part, fasten it, check the fit — rather than being labeled as one undifferentiated clip. That step-level structure is what lets a training pipeline learn the individual steps inside a procedure and the order between them, not just recognize that “a procedure happened.”

Variation

How are skipped, repeated and failed steps captured?

Failure and recovery cases are part of the same labeled structure as the clean version of a procedure: a skipped step, a repeated step, a step performed out of order, or a redo after a mistake. Representing how a real contributor deviates from and corrects the procedure, not only the version where every step happens once in order, is part of what a written spec can call out as a requirement for a batch.

A completion check — whether the procedure was finished correctly — is labeled as part of that same structure, so the delivered data distinguishes a complete, correct attempt from one that was abandoned or finished incorrectly.

Consistency

How is consistency kept across contributors and batches?

The written skill spec is the control for consistency: it names the procedure’s steps, their order, and their boundaries once, and every contributor and every batch is captured and labeled against that same definition. QA review before delivery checks calibration, sync, and labels against the spec’s accept criteria, so step boundaries labeled in one batch match the definitions used in another.

Variation between contributors on the same procedure — different grip, pace, or sequence for a flexible step — is expected and captured as real variation rather than treated as an error, as long as it falls within what the spec defines as an acceptable completion of the procedure.

Privacy

Who owns the data and how is it licensed?

The buyer. Every custom collection, including a procedural program, is delivered under a perpetual, non-exclusive commercial license by default, with exclusivity available, so the finished dataset can be trained on and productized without a research-only or unstated licensing arrangement.

Every episode is linked to a signed contributor release under a documented consent chain, and faces and screens anywhere in frame are detected and irreversibly blurred at ingest, with a reviewer confirming the result before anything is delivered. Delivery is billed and licensed against the accept criteria named in the written spec, with rejected items recaptured at no cost to the buyer before anything ships. Pricing is quoted per spec rather than published as a flat rate; see the pricing page for how a quote is built.

Delivery formats

What formats does procedural data ship in?

Procedural data ships in the same formats available for any custom collection on this site: RLDS, LeRobot, and WebDataset, plus HDF5, zarr, and Rerun .rrd, or raw streams with metadata if your pipeline needs the unprocessed form. Step order and boundaries are carried in the action-segment and episode structure of the delivered data rather than requiring a separate schema. Readable converter source ships alongside the data, so the schema can be retargeted to your own loader.

Getting started

How do you start a procedural capture project?

Describe the procedure, its steps and order, and the failure or variation cases your training pipeline is missing. That becomes a written spec covering the step list, setting, participant mix, capture tier, annotation depth, and accept criteria, quoted for reach, timeline, and price before capture begins.

From there the program runs through the same end-to-end pipeline as every Firsthand collection: contributor recruiting, capture against the spec, per-batch QA, anonymization, and licensed delivery, with on-demand top-ups available afterward against the same accept criteria.

At a glance

What you get.

Starting point
Written skill spec naming the procedure, its steps, and their order
Step structure
Task decomposed into named steps with start/end boundaries
Streams
Head/wrist RGB, depth, IMU, 3D hand pose, action segments, as specced
Privacy
Faces and screens blurred at ingest; undeidentifiable clips discarded
QA
Calibration, sync, and label review before delivery
License
Perpetual, non-exclusive, buyer-owned by default
Formats
RLDS, LeRobot, WebDataset, HDF5/zarr, Rerun RRD

Every collection runs through the same seven-stage end-to-end custom collection pipeline. End-to-end custom data collection is a managed service that takes an AI data need from problem to owned dataset in a single accountable pipeline.

Procedure structure

Procedure element × how it appears in the delivered data

Elements of a procedure and how each is represented in the delivered skill spec, labels, and data structure.
Procedure elementHow it appears in the delivered data
StepNamed step in the skill spec, labeled as an action segment with start/end boundaries
Sub-stepFiner-grained action segment nested within a step’s boundaries
Step orderSequence encoded in the ordering of action segments within an episode
Tool or object usedNamed in the skill spec; associated with the relevant action segment
Error and recoveryLabeled action segment capturing the deviation and the corrective action
Completion checkLabel on the episode indicating whether the procedure finished correctly

Capture constraints

Procedural-capture concern × how the process handles it

Constraints specific to capturing multi-step procedures, and how the written-spec, labeling, and QA process addresses each.
Procedural-capture concernHow the process handles it
Step variation between contributorsSpec names the procedure once; multiple contributors captured performing it to represent real variation within accept criteria
Ambiguous step boundariesAction segments mark explicit start/end points per step, reviewed against the spec’s definitions during QA
People in frameFaces and screens blurred at ingest; undeidentifiable clips discarded rather than shipped
Consistency across batchesSame written spec and accept criteria govern every batch; QA checks labels against those definitions before delivery

FAQ

Procedural task video data, answered.

What is procedural task video data?
First-person video and synchronized sensor data of a multi-step task performed in a fixed or partly fixed order, labeled into action segments that mark each step’s boundaries, episodes grouping a full attempt, and hand pose.
How is this different from the enterprise workflow data page?
The enterprise workflow page is about capturing an organization’s SOPs and business processes end to end. This page is about procedure structure specifically — step order, boundaries, variation, and completion — which applies to any multi-step task, not only an enterprise SOP program.
How is this different from action-labeled egocentric video?
Action-labeled egocentric video covers action-segment and hand-pose labeling generally, often for pretraining at scale. This page focuses specifically on procedures with a defined step order, including how skipped, repeated, and corrected steps are represented.
Can you capture a procedure with some flexible steps and some strictly ordered ones?
Yes. The written spec states which steps are strictly sequential and which can happen in either order, and that structure carries through into how the action segments are labeled.
How are skipped or repeated steps handled in the data?
They are part of the same labeled structure as a clean attempt — a skipped step, a repeated step, or a redo after a mistake is captured and labeled, which a written spec can call out as a requirement for the batch.
Who owns procedural data captured this way, and how is it licensed?
The buyer. Delivered data carries a perpetual, non-exclusive, buyer-owned commercial license by default, with exclusivity available, the same as any other custom collection on this site.
Which formats does procedural data ship in?
RLDS, LeRobot, and WebDataset, plus HDF5, zarr, and Rerun .rrd, or raw streams with metadata — the same formats available for any custom collection, with readable converter source included.
How do you start a procedural capture project?
Describe the procedure, its steps and order, and the failure or variation cases your training pipeline needs. That becomes a written spec quoted for reach, timeline, and price, typically starting with a Spec Pilot before scaling to full volume.
Sources

Where are these procedural data formats documented?

Need a custom procedural task dataset?

Tell us the procedure, its steps and order, and the failure cases your training pipeline needs covered. We will turn it into a written skill spec and run a Spec Pilot before scaling to a full collection.