Cutting and food prep

Egocentric Cutting and Food Prep Video Data (Slicing, Chopping, Peeling)

Knife work is where a food-prep robot meets its hardest problem: two hands doing different jobs, a blade, and an ingredient that changes shape with every cut. We collect custom egocentric video of slicing, chopping, dicing and peeling on demand, to a written skill spec, with synchronized streams, action segments, anonymization and a buyer-owned license.
Tasks
Chop, peel, slice and knife work in real kitchens
Streams
Ten, synced under 2 ms
First batch
Median 48 h in deep-coverage settings
License
Perpetual, buyer-owned
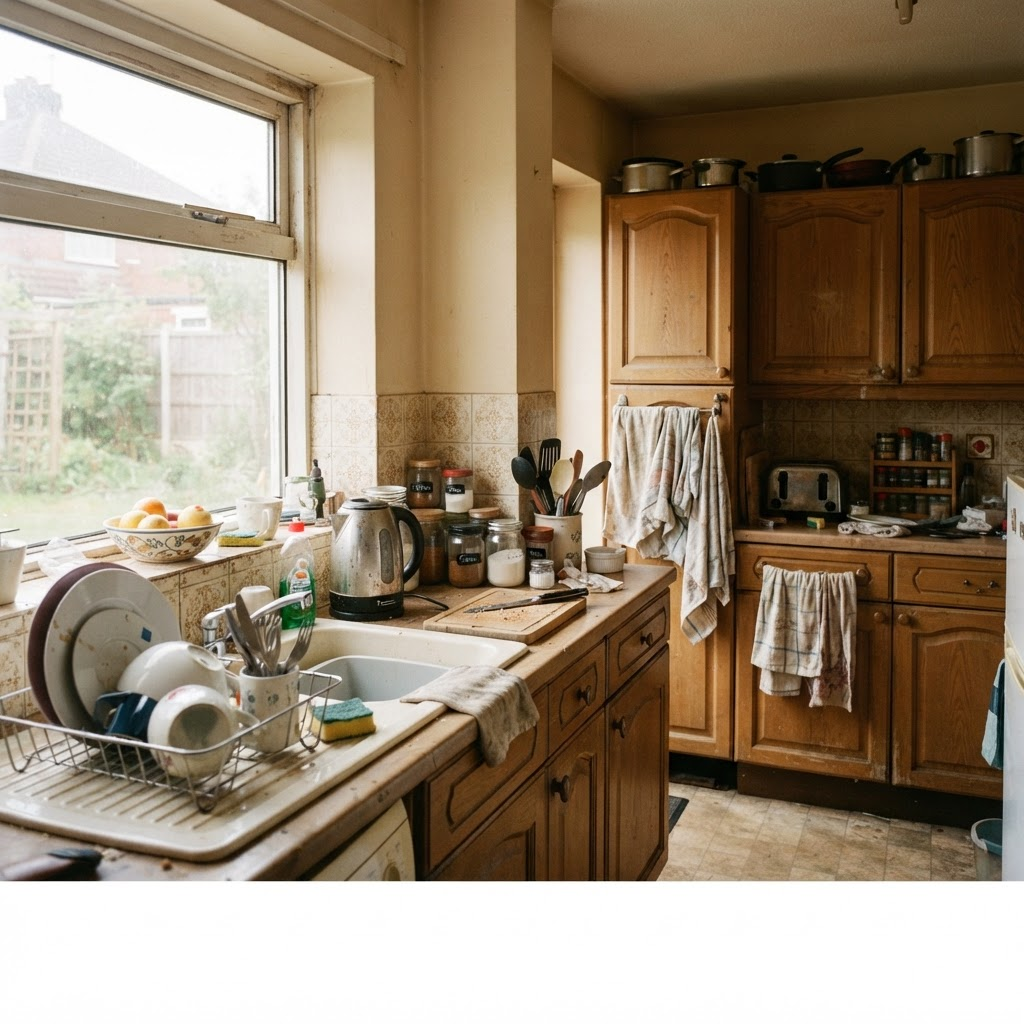
A real lived-in domestic kitchen with everyday clutter on the countertops, seen from the first-person viewpoint of someone preparing food.
Food-prep capture happens in real kitchens, from the cook’s own point of view, because that is the view a robot working at the counter would have.

Requirements

What does knife-work capture need that a generic kitchen clip does not?

01

Both hands and the cut in view at the same moment

One hand holds the tool and the other steadies the ingredient. First-person capture keeps both hands, the blade and the food in frame, and 3D hand pose carries a per-joint visibility flag so a finger curled behind a handle is flagged rather than guessed.

02

A spec that names the cut, not just the kitchen

The site’s skill-spec guide says to name the verb and the noun rather than a broad activity. A spec for this family names the cut type, the ingredient and where one completed cut starts and ends, so each cut can become its own labeled segment.

03

Masks that follow an ingredient as it changes shape

Produce does not track well with masks propagated frame to frame the way a rigid tabletop object does, so food-prep captures ship per-frame instance masks instead.

04

Reject rules written before capture, not after

An item is rejected when the cut is off-frame, a second person’s hands enter the manipulation region, or depth is invalid over too much of the board region. The thresholds are agreed in the spec, so the batch is judged against terms you signed.

Definition

What is egocentric cutting and food prep data?

Egocentric cutting and food prep data is first-person video of a person slicing, chopping, dicing or peeling food, recorded from the contributor’s own point of view with synchronized sensor streams alongside. The camera sits on the head, close to what a robot’s onboard camera would see over a cutting board, so the frames show what the hands are doing to the ingredient and the tool rather than a distant view of someone standing in a kitchen. On this site it is a custom collection: you name the cut, the ingredient and the setting, and capture is run to that written skill spec.

The data is human capture. A paid, consented contributor wears the rig and performs the task. It is not robot or teleoperation data, and it is not a fixed corpus you download. This page is narrower than egocentric cooking video, which covers food preparation as a whole, and narrower than kitchen pretraining at scale and food-service capture, each of which has its own page. The subject here is the cutting family of food-prep tasks: which of them the site states it can capture, how they are specified, what makes them hard to record, and how the episodes are labeled and checked before delivery.

The phrases people use for this are close cousins: a food prep video dataset, egocentric slicing and chopping video, cutting robot training data, or custom food preparation data collection. They describe one request from different angles. Whichever wording you start from, the work is the same: write down the cut, collect it on demand from real kitchens, and receive validated episodes with the labels a training pipeline expects.

Why it matters

Why do robots need first-person video of slicing, chopping and peeling?

NVIDIA’s GR00T N1 paper describes a data pyramid with web data and human video at the base, synthetic data in the middle and real robot trajectories at the top. First-person human video of food preparation sits in that base layer. It is far more abundant than robot data, and a person can work through many kitchens without the safety and access problems of putting an early-stage robot near knives, hot surfaces and hot liquids. For cutting specifically that safety point is the practical case for human capture: the demonstrations come from people, in the kitchens where the robot will eventually work, and nobody has to supervise an unfinished robot holding a blade.

Cutting is also a clean test of manipulation skill because it is bimanual by default. The site describes knife work as exercising fine bimanual dexterity, tool grip and control, and notes that chopping, pouring and transferring a loaded pan are bimanual in a kitchen, so a spec has to name bimanual coordination explicitly rather than treat it as a rare case captured incidentally. A single clip of a hand on a knife does not carry that. Both hands, their relationship to each other and to the ingredient, and the moment the blade meets the food all have to be present in the episode.

Variety across people matters as much as variety across kitchens. Capturing the same tasks performed by different people, at different paces and with different habits, including left- and right-handed knife work and different chopping styles, keeps a model from overfitting to one person’s technique. Generalist’s GEN-0 write-up makes a related point in different words: "data quality and diversity matters more than sheer volume." A corpus that repeats one board, one knife and one person does not generalize better than one that visits many distinct kitchens and contributors.

Public corpora are captured for someone else’s task distribution. EPIC-KITCHENS-100 is the reference example: its paper describes 100 hours of unscripted footage from 45 kitchens recorded with head-mounted cameras, and its authors report that adding more data saturated and that the results highlight the need for more diverse data rather than merely more data. A custom collection lets you aim at the cut, the ingredient and the setting your model is missing, instead of hoping a public release happens to contain them.

Food-prep tasks

Which food-prep tasks can be captured?

Four rows of the site’s commercial task catalog name a cutting task explicitly. Each is listed with a skill level, a capture setup and a status exactly as the catalog states them, and the table below reproduces them. In the restaurant and commercial kitchen environment the catalog lists chopping and portioning vegetables with a chef’s knife and cutting board, described as washing, trimming and chopping vegetables into even pieces and portioning them into containers, and a broader culinary chef and knife-work task described as breaking down produce and proteins with precise knife cuts and cooking dishes on a professional line. Both are marked as active collection.

In the working kitchen set for food prep the catalog lists peeling and chopping vegetables with a knife, and slicing bread and spreading a condiment. Both are marked as available on request. Peeling appears only in that peel-and-chop row, and slicing as its own task appears only in the bread row, so those are the two phrasings to use when you want to cite what the site already states. Alongside these, the kitchen task categories documented on the site include knife work: dice, julienne and chiffonade.

Neighboring food-prep rows exist that do not name a cut. Back-of-house food preparation, staging, portioning and storage is listed as a food prep task, and catering lists bulk food preparation of vegetables, proteins and sauces in large batches. Those fit a spec that includes cutting as one step, but the catalog does not describe a cut in them, so this page does not claim one. The site’s skill-spec guide offers a worked example of the shape a cutting spec takes: dicing an onion with a chef’s knife, requiring both hands visible at grasp and first cut and budgeting hours across daylight, low light, cluttered and failure-case conditions.

A cut, ingredient or technique outside those rows is a skill-spec question to settle in a Spec Pilot rather than an assumption. The catalog is a list of what is captured or available, not a ceiling on what can be briefed.

Capture setup

What capture setup and streams are used?

A food-prep collection uses the same capture stack as every Firsthand program. The instrumented tier is a head-mounted stereo rig that records first-person RGB, with a metric depth stream recovered from the calibrated stereo rig rather than from a standalone depth sensor, and 6-DoF IMU data at 200 Hz from head- and wrist-mounted sensors. The wider stack is ten streams: a 4K head camera, two wrist cameras, depth, IMU, 3D hand and body pose, instance segmentation and action labels, hardware-aligned under 2 ms. The two wrist cameras give a second, closer view of the hands than the head camera alone, which matters when a hand wraps around a handle.

Every stream is hardware-triggered onto one PTP clock domain, so depth, motion and hand pose line up with the same video frame rather than being approximated afterwards. The rig is calibrated twice per session, before capture starts and after it ends, and an episode is accepted only if RMS reprojection stays under 0.28 px. The catalog lists the capture setup per task: a head-mounted phone or multiview rig for the restaurant and commercial kitchen rows, and a multiview rig with handheld grippers for the food-prep working-kitchen rows. Which tier applies to your program is set in the skill spec.

Depth is the stream to plan around in a kitchen. Wet and reflective surfaces degrade it, and a rinsed board or steel sink is exactly where cutting happens, so kitchen episodes ship per-frame depth confidence maps and you can mask low-confidence regions instead of trusting them. An episode with more than 35 percent invalid depth pixels in the manipulation region goes to the reject log. Heat is not sensed, force and tactile readings are not among the streams, and no robot or teleoperation data is captured.

Labels

Which labels and annotations are available?

Each attempt is delivered as one episode. Inside it, action segments divide the episode into start- and end-timestamped spans, each carrying start_ns, end_ns, verb and noun. For this task family, a segment can be one cut as written in the skill spec, so a dice becomes a sequence of labeled cuts rather than one long clip. The other standard fields are hand_joints and hand_visible for 3D hand pose, contact_events for the moment the hand meets the item, objects, and instance_masks, stored at the depth resolution of 848×480 so they line up with the depth stream.

Hand pose is delivered for both hands with a per-joint visibility flag for occluded fingers. That is the label that carries the bimanual structure of cutting: where the guiding hand sits relative to the blade hand across the whole cut. Contact events mark when the hand meets the ingredient or the tool, and per-frame instance masks follow produce as it changes shape instead of relying on masks propagated between frames.

The site does not list labels for the quality of a cut. There is no stated label for cut thickness, uniformity or evenness, no stated food-state label such as doneness or temperature, and no stated ontology of cuts beyond the verb and noun on each action segment. If your pipeline needs a cut-type taxonomy, the verb and noun vocabulary is something the skill spec defines with you, and anything beyond it is a scoping conversation, not a delivered field.

QA, consent and safety

How do QA, consent, safety and anonymization apply?

Validation runs against signed accept criteria written into the spec before capture. Each batch goes through per-batch QA and a reject log ships with it. Episodes are machine-checked against stated reject criteria: a sync breach beyond the ceiling for more than three consecutive frames, calibration drift beyond tolerance, the manipulated object out of frame for more than 15 percent of the episode, more than 35 percent invalid depth pixels in the manipulation region, an undocumented bystander, or a mismatch against the named skill spec. A human reviewer then checks each episode against the task spec. The worked dicing example in the skill-spec guide adds the shape of a cutting-specific reject rule: an item is rejected when the cut is off-frame for more than two seconds or a second person’s hands enter the manipulation region.

Only footage that clears the criteria is billed as a validated hour, and rejected items are recaptured at our cost. Many teams start with a Spec Pilot, a small, fast first batch that proves the spec and the accept criteria on real footage before volume scales.

Capture happens inside lived-in or working kitchens. Every contributor signs a written release before capture, and each delivered episode links to that record through consent artefact IDs in the batch data card. The consent chain has six checkpoints, from before capture to after delivery, and a break at any one discards the footage rather than shipping it at a lower grade. At ingest, automated detection finds faces, plates and screens and blurs them irreversibly, and speech is scrubbed of names, addresses and card numbers while ambient audio is kept. A human reviewer confirms that no un-consented person is identifiable in any frame, and footage that cannot be de-identified is discarded.

On safety, the site’s stated point is about the robot, not the contributor: human capture avoids running an early-stage robot near knives. A contributor knife-handling protocol is not stated on this site, so this page does not describe one. None of this is legal advice, and the executed agreement controls.

Delivery and speed

How fast can a custom food-prep dataset be delivered?

From signed spec to first validated batch, the timeline is a median of 48 hours where coverage is deep and three to four weeks where it is thin and contributors need to be recruited first. Speed comes from a warm pipeline, not from cutting consent, review or anonymization. After the first batch, on-demand top-ups run against the same accept criteria, so you can add more cuts, ingredients, kitchens or variation without rewriting the spec. The site does not state a turnaround for those later batches, so plan them in your quote.

Delivery is in the format your stack already reads: RLDS, LeRobot, WebDataset, HDF5, zarr or Rerun .rrd, or raw streams with metadata. Readable converter source ships alongside the data so the schema can be retargeted to your own loader. Collections are billed per validated hour.

The license is perpetual, irrevocable and worldwide, with the data buyer-owned and non-exclusive by default. Training, evaluating, fine-tuning and deploying models, including commercial ones, is permitted, and exclusivity is available as a separate term. The executed agreement controls. The site does not publish a price list, a minimum order, or a batch size for this task family, so those are set in your quote.

Not stated

What does a cutting and food-prep collection not include?

Where this site does not state something, this page says "not stated" rather than filling the gap. The table below separates what is delivered from what is not stated. There is no listed label for cut quality, thickness or uniformity, no food-state label such as doneness or temperature, no force, tactile or thermal stream, and no blade-contact force value. Nothing here claims a training outcome or a model improvement.

The tradeoff to plan for is the embodiment gap between a human hand and a robot end-effector, which retargeting or pairing with robot data has to close. What you get is human first-person demonstrations in which the hands, the ingredient and the step structure are explicit. Counts of kitchens, contributors, hours and cuts are not fixed numbers on this site; they are set in your skill spec.

Getting started

How do you scope and request a custom food-prep dataset?

Describe the cuts or food-preparation tasks, the ingredients, the kitchen types and the failure or variation cases your pipeline is missing. That becomes a written skill spec, quoted for reach, timeline and price before any capture begins, and most programs run a Spec Pilot first. The scoping checklist below maps the five parts of a skill spec onto a cutting request. A published home-cooking sample recording is on the sample data outputs page if you want to see the streams before you write a spec.

Three choices matter most for this family. Name the cut and the ingredient rather than a broad activity, because that is what lets each cut become one action segment. Name the kitchen types and the participant mix, since different kitchens present different boards and clutter, and different people cut differently. And name the lighting: daylight coverage fills fastest, while evening, low-light capture is the harder cell to fill.

Capture setup

What is the capture setup for a cutting and food-prep collection?

The capture setup as stated on this site, applied to food prep. Counts of kitchens, contributors and hours are set in the skill spec.
PartAs stated on this site
Instrumented rigHead-mounted stereo rig worn by the contributor; first-person RGB
StreamsTen: 4K head camera, two wrist cameras, depth, IMU, 3D hand and body pose, instance segmentation, action labels
SyncHardware-triggered onto one PTP clock domain; aligned under 2 ms
DepthMetric depth recovered from the calibrated stereo rig; per-frame depth confidence maps for kitchens
IMU6-DoF at 200 Hz from head- and wrist-mounted sensors
CalibrationTwice per session; accepted only under the 0.28 px RMS reprojection gate
MasksPer-frame instance masks, stored at 848×480
Catalog capture setupPhone (head-mounted) or multiview rig for restaurant kitchen rows; multiview rig with handheld grippers for food-prep working-kitchen rows

Every collection runs through the same seven-stage end-to-end custom collection pipeline.

Task variations

Which cutting tasks does the catalog name, and what is captured?

The four catalog rows that name a cutting task, reproduced as the catalog states them, followed by the documented knife-work category.
Task (as listed)Description (as listed)EnvironmentSkill levelCapture setupStatus
Chop and portion vegetables using a chef’s knife and cutting boardWash, trim and chop vegetables into even pieces and portion them into containers.Restaurant & Commercial KitchenMediumPhone (head-mounted) / multiview rigActive collection
Culinary Chef Work / Knife WorkBreak down produce and proteins with precise knife cuts and cook dishes on a professional line.Restaurant & Commercial KitchenHardPhone (head-mounted) / multiview rigActive collection
Peel + chop vegetablesPeel and chop vegetables with a knife.Working Kitchen Set (food prep)MediumMultiview rig + handheld grippersAvailable on request
Slice + spreadSlice bread and spread a condiment.Working Kitchen Set (food prep)MediumMultiview rig + handheld grippersAvailable on request
Knife work: dice, julienne, chiffonadeDocumented kitchen task category; exercises fine bimanual dexterity, tool grip and control.Domestic kitchens, shared-house kitchens, small commercial prep linesNot statedSet in the skill specDocumented task category

Streams and labels

Which streams and labels are delivered for knife work, and which are not stated?

Delivered items are stated elsewhere on this site. Items marked not stated are not promised on this page.
Stream or labelWhat it gives a cutting episodeStatus
Head and wrist camerasFirst-person view of the cut plus a closer view of the handsDelivered
Depth with per-frame confidence mapsBoard and ingredient geometry; low-confidence regions can be maskedDelivered
6-DoF IMU at 200 HzHead and wrist motion aligned to the video frameDelivered
3D hand pose with per-joint visibility flagsBoth hands across the cut; occluded fingers flaggedDelivered
Contact eventsThe moment the hand meets the itemDelivered
Action segments (start_ns, end_ns, verb, noun)One labeled span per cut or sub-stepDelivered
Per-frame instance masks (848×480)Ingredient masks that follow a changing shapeDelivered
Consent artefact IDs and anonymization recordProvenance per episodeDelivered
Cut-quality, thickness or uniformity labelNot listedNot stated
Food-state label (doneness, temperature)Not listedNot stated
Force, tactile or thermal readingsNot among the listed streamsNot stated
Robot or teleoperation dataHuman first-person demonstrations onlyNot captured
Counts of kitchens, contributors, hours and cutsSet per program in the skill specNot stated

Scoping checklist

What does a cutting request put into each part of a skill spec?

The five parts of a skill spec as the site’s guide describes them, applied to a cutting request. The dicing example is the guide’s worked example; your own fields and numbers are agreed with you.
Skill-spec partWhat to name for a cutting requestFrom the guide’s dicing example
Named skillThe verb and the noun: the cut and the ingredient, not "cooking"Dicing an onion with a chef’s knife
Geometry that must be visibleWhat must be in frame and for how long: both hands, the blade, the boardBoth hands visible at grasp and first cut
Condition budget in hoursHours per condition cell, including failure cases, and the kitchen typesHours budgeted across daylight, low light, cluttered and failure-case conditions
Reject ruleThe conditions that fail an item, written firstCut off-frame for more than two seconds; a second person’s hands in the manipulation region; depth invalid over 35% of the board region
Acceptance testOne test that decides whether an attempt counts as completeYour acceptance test is agreed in the spec
Participants and lightingHandedness, technique and pace; daylight or low lightSet per program in the skill spec

FAQ

Egocentric cutting and food prep video data, answered.

What is egocentric cutting and food prep video data?
Custom first-person video of people slicing, chopping, dicing and peeling food, captured by paid, consented contributors wearing a capture rig and doing the tasks in a written skill spec, and delivered with synchronized streams, hand pose, action segments and consent and anonymization records.
Which cutting and food-prep tasks does Firsthand capture?
The site’s task catalog names chopping and portioning vegetables with a chef’s knife and cutting board, culinary chef and knife work, peeling and chopping vegetables with a knife, and slicing bread and spreading a condiment, alongside the documented knife-work category of dice, julienne and chiffonade. Anything else is settled in the skill spec and a Spec Pilot.
What streams and labels come with a knife-work episode?
Ten hardware-synchronized streams, including head and wrist cameras, depth with confidence maps, IMU, 3D hand pose and instance masks, plus action segments with start_ns, end_ns, verb and noun, hand pose with visibility flags and contact events.
Do you provide cut-quality, force or food-state labels?
Not stated. The delivered fields are action segments, 3D hand pose with visibility flags, contact events, objects and per-frame instance masks, plus depth confidence maps. No cut-quality, thickness, force, tactile, thermal or food-state data is listed.
How is a cutting dataset checked before delivery?
Episodes are machine-checked against reject criteria written into the spec, such as the object out of frame for more than 15 percent of the episode or more than 35 percent invalid depth pixels, then reviewed by a human against the task spec. A reject log ships with each batch, and only footage that clears the criteria is billed as a validated hour.
How are consent and privacy handled when filming in kitchens?
Every contributor signs a release and every episode links to it. Faces, plates and screens are detected and irreversibly blurred at ingest with reviewer confirmation, and footage that cannot be de-identified is discarded. The executed agreement controls, and this is not legal advice.
How fast can a custom food-prep dataset arrive?
A median of 48 hours from signed spec to first validated batch where coverage is deep, and three to four weeks where it is thin. The site does not state a turnaround for later top-up batches.
Who owns the data, and what formats are offered?
The buyer owns the delivered data under a perpetual, irrevocable, worldwide, non-exclusive commercial license by default, with exclusivity available as a separate term. Delivery is in RLDS, LeRobot, WebDataset, HDF5, zarr or Rerun .rrd, or raw streams with metadata.
Sources

Where are these food-prep capture claims documented?

Request a custom cutting and food-prep dataset.

Tell us the cuts or food-preparation tasks, the ingredients and the kitchen types your model needs to see. We will quote reach, timeline and price against a written spec, with a first validated batch in a median of 48 hours where coverage is deep.