Manufacturing & workshop

Manufacturing Workflow Data for AI and Robotics

A production procedure is rarely one skill — it is a sequence of fastening, measuring, fitting, and inspection steps that have to run in order, with their own failure modes along the way. Manufacturing workflow data captures that whole sequence first-person, against a written skill spec that decomposes the procedure into step units, labels each with action segments and hand pose, and covers the failure and recovery cases a policy trained only on clean runs would never see.
Starting point
Manufacturing SOP written into a skill spec
Step structure
Task decomposition → action segments → episodes
First batch
a median of 48 hours (deep coverage)
License
Perpetual, buyer-owned, non-exclusive by default
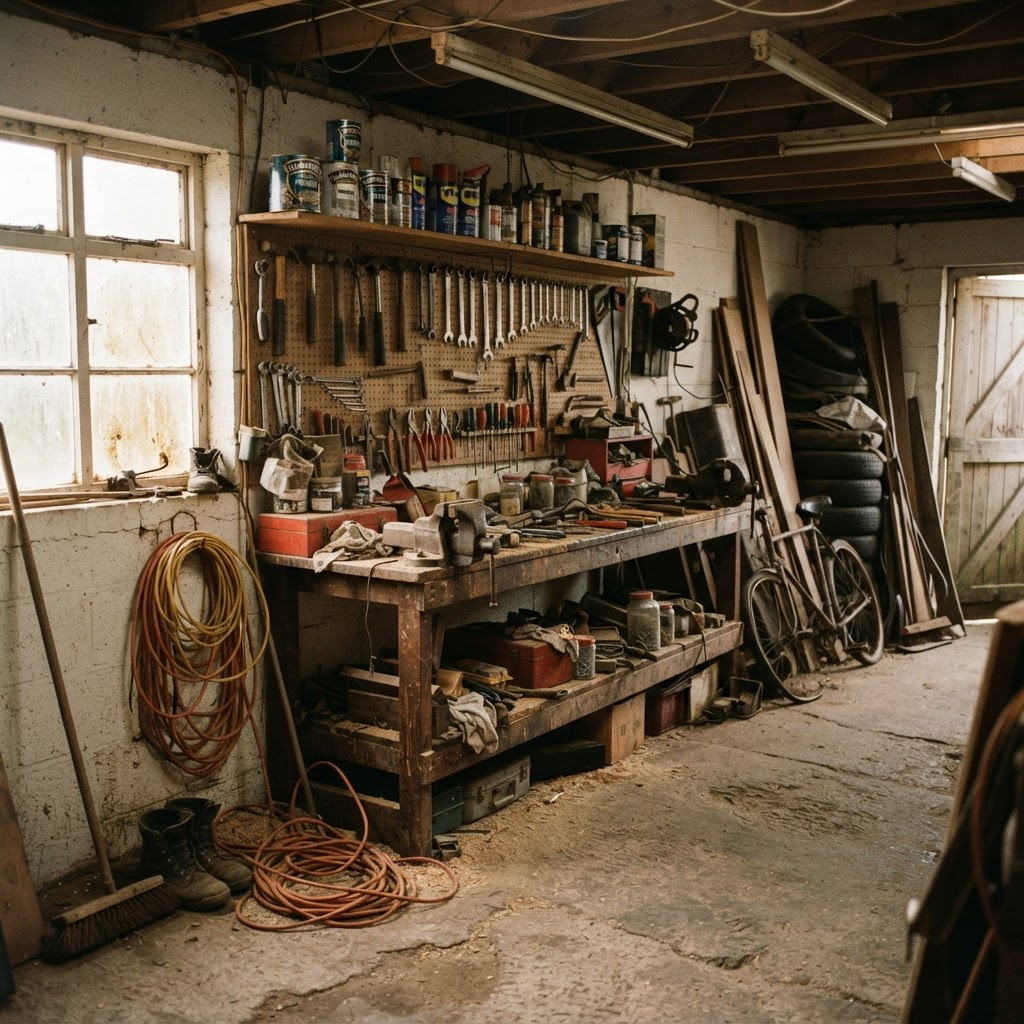
A garage workshop bench with a vise, hand tools on a pegboard and real clutter, representing a multi-step manufacturing procedure.
A multi-step manufacturing procedure is captured as one continuous workflow, with each step labeled as an action segment against the written skill spec.

Why capture the whole workflow

What a multi-step manufacturing procedure needs that a single skill does not.

01

A procedure is a sequence, not one motion

Fastening, measuring, fitting, and inspection steps on a production line have to run in a defined order, each with its own completion check. Capturing them separately as isolated skills loses the sequencing and hand-offs between steps that a workflow-level policy needs to learn.

02

Steps need boundaries within one continuous run

Task decomposition breaks the overall procedure into step-sized units before capture starts, and a full run of the workflow is captured as one episode with action segments marking where each step begins and ends — so a continuous capture still yields individually labeled steps.

03

Variation between operators is expected, not a defect

Two operators rarely perform the identical physical motion for the same step. The written spec and its accept criteria define what counts as a correct completion of a step, not a single reference motion, so variation within that bound is captured as normal coverage rather than rejected.

04

Failure and recovery are part of the real procedure

A real production workflow includes a step going wrong — a fastener missed, a part seated incorrectly — and the operator correcting it, not only the clean path. Failure case coverage captures those recovery moments deliberately where the spec calls for them.

Fit

What is manufacturing workflow data?

Manufacturing workflow data is first-person capture of a real production or assembly procedure — a sequence of fastening, measuring, press-fit, and inspection steps performed in order on a bench or at a production cell — rather than any single one of those steps in isolation. The procedure is written into a skill spec that names the task units, scenes, streams, and accept criteria the collection needs to cover, the same spec format used for any custom order on this site.

This differs from a single named assembly skill: a fastening sequence or a press-fit step captured on its own is assembly task data, while the same steps captured together as one multi-step production procedure, with the sequence and hand-offs between them preserved, is workflow data. Both run through the same tool use and assembly setting and the same capture, QA, and licensing process.

Need

Why do manufacturing AI and robotics teams need first-person workflow video?

A model trained only on isolated skill clips has no record of how those skills chain together, in what order, or what one step’s completion looks like as the trigger for the next. A production procedure captured as a single first-person workflow preserves that sequence, the hand-offs between steps, and the pacing of a real operator moving through the full task rather than resetting between clips.

Public benchmark datasets for bimanual precision are typically licensed for research only and forbid derivatives, so they cannot legally reach a commercial production model. Custom workflow capture is written against the buyer’s own procedure and shipped under a buyer-owned license that can go into a shipped product.

Scoping

How is a manufacturing SOP turned into a skill spec?

The procedure, whatever form it exists in today, from a formal SOP document to an experienced operator’s know-how, is described in terms a capture program can act on: which steps make up the workflow, which tool or part variants and bench setups it needs to cover, which streams the training approach consumes (RGB plus depth, 3D hand pose, and contact events for most assembly-bench work), and the accept criteria a captured take has to clear for each step.

Writing the spec is also where ambiguity in the original SOP gets resolved: where a document is vague about a step boundary or a completion check, the spec states it explicitly, so the people reviewing captured footage against the spec and the people who performed the original procedure are judging completion against the same written definition.

Structure

How are multi-step workflows segmented and labeled?

Task decomposition breaks the overall procedure into step-sized task units before capture starts, each with its own description, tools or parts involved, and completion check in the written spec. A full run of the procedure is then captured as an episode, and action segments mark where each task unit begins and ends within that episode, so one continuous capture of the whole workflow still yields individually labeled steps.

3D hand pose is captured through reach, grasp, and place for steps defined by a specific grip, tool orientation, or press-fit motion, with contact and grasp events recorded at the point of fastening or fitting. Where a step is prone to going wrong, failure case coverage captures the error and the operator’s recovery as its own labeled segment, rather than only the clean completion path.

Capture setup

Which capture setup is used for manufacturing workflow data?

A head-mounted camera keeps the fastening, measuring, and fitting motion in frame from the viewpoint a manufacturing policy will actually see from, with depth, 3D hand pose, contact events, and action segments aligned to video on one hardware clock under 2 ms, the same multi-stream setup used for assembly task data on this site.

Small fasteners and fine parts push below the practical resolution of some depth sensors — metric depth on sub-centimetre parts is flagged rather than interpolated, while hand pose stays valid at that range, so the stream boundaries are stated rather than papered over with uncalibrated depth.

Coverage

How are failure and recovery steps covered?

A real manufacturing workflow includes the step going wrong — a fastener missed, a part seated incorrectly, a measurement out of tolerance — and the operator catching and correcting it. Where the written spec calls for failure case coverage, those moments are captured deliberately as their own labeled segment within the episode, alongside the clean completion path, rather than discarded as a bad take.

A policy trained only on clean runs of a procedure has nothing to learn from when a step does not go as planned on a real production line; capturing the error and recovery together is what gives a workflow-level model a recovery behavior to fall back on.

Privacy

How are operators and bystanders protected during capture?

Every contributor performing a workflow signs a documented release as part of a consent chain, and that record travels with the data through delivery. Faces, plates, and screens in the capture environment are detected and irreversibly blurred at ingest, and a human reviewer confirms the anonymization result before anything ships, with the anonymization record delivered alongside the data.

Manufacturing workflow capture often happens on a real bench or production cell where other operators, documents, or screens may appear in frame incidentally rather than as the subject of the recording. The same detect-and-blur anonymization step applies to anything caught in frame, not only to the contributor performing the task.

Licensing

Who owns the workflow data and how is it licensed?

The buyer. Delivered manufacturing workflow data ships under a perpetual, buyer-owned, non-exclusive commercial license by default, with exclusivity available so a given workflow collection is not resold to another buyer. That license is what lets a model trained on the captured workflow ship in a commercial product rather than carrying research-only restrictions.

Provenance and data-processing documentation accompanies the license: the provenance page sets out what is actually delivered and the consent and anonymization checkpoints applied to every episode, and the DPA covers data-processing terms for the engagement.

Formats

What is delivered and in which formats?

Finished manufacturing workflow data delivers in RLDS, LeRobot, WebDataset, HDF5, zarr, or Rerun .rrd, or as raw streams with metadata — the same set of formats available on any custom order, chosen to match whatever a training pipeline already consumes. RLDS and LeRobot are built around episodic, step-based sequences, which maps directly onto a procedure already decomposed into task-unit episodes with action-segment labels.

Because the episode and action-segment structure is set at the spec stage rather than reverse-engineered after capture, the same captured workflow can be re-exported into a different one of these formats later without recapturing, if a training pipeline changes.

Getting started

How do you start with a Spec Pilot?

Start by describing the manufacturing procedure you need captured — whatever form it exists in today — and the steps, tool or part variants, and streams your training pipeline needs. That becomes a written skill spec, and the program typically starts with a Spec Pilot: a small, fast first batch captured against the spec, QA’d against the same accept criteria a full order gets, and delivered with its reject log before you commit to full volume.

A median of 48 hours from signed spec to first validated batch applies where coverage of the bench or production-cell setting is already deep; where the procedure requires contributors recruited into a new environment from scratch, a realistic timeline runs three to four weeks. The same written spec that scoped the pilot scales directly into production volume once it is reviewed and accepted.

At a glance

What you get.

Starting point
Manufacturing SOP or procedure written into a skill spec (steps, scenes, streams, accept criteria)
Step structure
Task decomposition into step units, each captured as part of one episode
Streams
RGB (head/wrist) • depth • 3D hand pose • contact events • action segments, as specced
First order
Spec Pilot — small, fast first batch
Billing
Per validated hour
License
Perpetual, buyer-owned, non-exclusive by default; exclusivity available

Every collection runs through the same seven-stage end-to-end custom collection pipeline. End-to-end custom data collection is a managed service that takes an AI data need from problem to owned dataset in a single accountable pipeline.

Workflow structure

How a manufacturing workflow element appears in the delivered data

Workflow element, where it is captured in the pipeline, and the labeled artifact it becomes in delivery.
Workflow elementCaptured asDelivered as
SOP stepA task unit defined in the written skill specA labeled episode or action segment
Sub-task within a stepA task-decomposition unitAn action segment boundary within the episode
Tool or part variantA scene/object variant named in the specAn object or instance-level label on the episode
Specific grip or manipulationA hand-pose requirement in the spec3D hand-pose label or stream alongside the episode
Fastening or fitting contactA contact-event requirement in the specA contact/grasp event label on the episode
Error and correctionA failure-case requirement in the specA labeled failure-case / recovery episode
Step completion checkAn accept criterion in the specThe QA checkpoint a captured take must clear before delivery

Scope comparison

Manufacturing workflow data vs single-skill assembly data vs pretraining-scale industrial data

How scope, labels, spec, QA, and intended use differ across the three related ways this site captures manufacturing and industrial tasks.
Manufacturing workflow dataSingle-skill assembly task dataIndustrial pretraining data
ScopeA full multi-step production procedure, sequence preservedOne named skill (fastening, measuring, press-fit) in isolationBroad coverage across many sites, stations, and tools
Spec unitOne skill spec covering the whole workflow as task-decomposed stepsOne skill spec per named skillMany specs spanning facilities and task families
LabelsAction segments per step, hand pose, contact events, failure/recovery per stepAction segments, hand pose, contact events for the one skillSame stream set, applied broadly rather than deeply on one procedure
QAAccept criteria per step, reviewed against the same written specAccept criteria for the one skillAccept criteria applied per site/station batch
Best fitTraining a policy on a sequenced production procedure, hand-offs includedTraining or benchmarking one skill in isolationPretraining a foundation model’s general prior before site-specific alignment

FAQ

Manufacturing workflow data, answered.

What is manufacturing workflow data?
First-person video of a real, multi-step production or assembly procedure, captured against a written skill spec, decomposed into step units through task decomposition, labeled with action segments and hand pose, and delivered under a buyer-owned commercial license.
How is this different from assembly task data?
Assembly task data captures one named skill — fastening, measuring, press-fit — in isolation. Manufacturing workflow data captures a full multi-step procedure as one sequence, with the order and hand-offs between steps preserved in the written spec and the labeled episode.
Does the workflow need to already exist as a formal written SOP?
No. A documented procedure, a training video, or an operator walking through the steps are all workable starting points — the capture program writes its own skill spec from whichever source is available.
Are mistakes and corrections captured, or only the clean version of each step?
Where the spec calls for it, failure case coverage deliberately captures a step going wrong and the operator’s recovery as its own labeled segment, alongside the clean completion path.
How are operators and anything else in frame protected?
Every contributor signs a documented release as part of a consent chain, and faces, plates, and screens anywhere in frame are detected and irreversibly blurred at ingest, confirmed by human review before delivery.
Who owns manufacturing workflow data captured this way?
The buyer. Delivered data carries a perpetual, buyer-owned, non-exclusive commercial license by default, with exclusivity available, rather than a research-only arrangement.
Which formats can manufacturing workflow data be delivered in?
RLDS, LeRobot, WebDataset, HDF5, zarr, or Rerun .rrd, or raw streams with metadata — the same formats available on any custom order, built around the same episode and action-segment structure.
How long does a first manufacturing workflow batch take?
A median of 48 hours from signed spec to first validated batch where the bench or production-cell setting’s coverage is already deep; roughly three to four weeks where new contributors need to be recruited into an unfamiliar environment.
Sources

Where are the delivery formats documented?

Need a manufacturing procedure captured as training data?

Tell us the production or assembly procedure and the steps your training pipeline needs covered. We will turn it into a written skill spec and run a Spec Pilot before scaling to a full collection.